Welcome, Linker Hand L6!
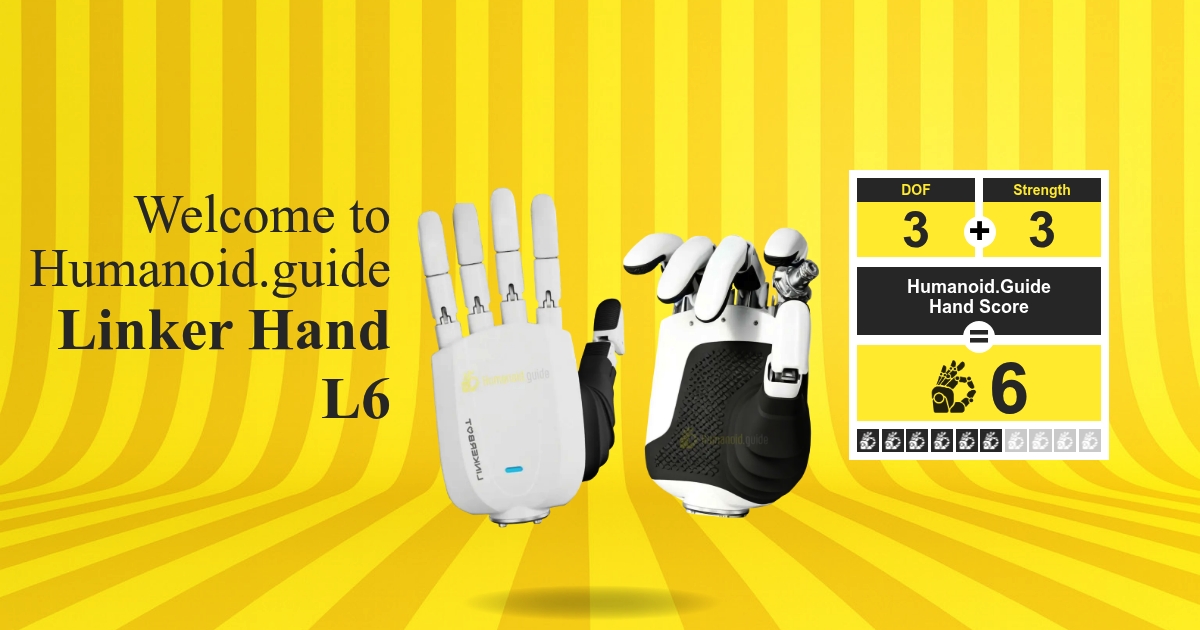
The Linker Hand L6 is a robotic hand from Chinese manufacturer LinkerBot, combining a compact mechanical design with an emphasis on dexterity and grip strength. Its overall Humanoid.Guide Hand Score is 6 out of 10, placing it in the capable category. Degrees of Freedom and Strength each receive a rating of 3 out of 5, giving the hand a balanced assessment across these two dimensions. These ratings describe evaluation tiers rather than physical joint counts or measured force. The hand weighs 607 grams and uses a rigid linkage transmission rather than a tendon driven mechanism. Its drive architecture combines a brushless motor with a ball screw linear drive, which LinkerBot describes as a super electric cylinder. The listed transmission efficiency is 90 percent. This mechanical configuration distinguishes the L6 within the broader field of robotic hands, where actuator selection, transmission design, mass, and packaging all influence the practical integration of a hand into a larger robotic system.
The L6’s equal category ratings offer a useful framework for understanding its technical positioning. A Degrees of Freedom rating of 3 out of 5 represents a middle tier dexterity assessment, while its Strength rating of 3 out of 5 places strength at the same level within the scoring system. Neither rating should be read as a direct measurement of motion range, joint independence, payload, or contact force. Together, they support a balanced characterization rather than a claim of exceptional performance in either category. The overall score of 6 out of 10 identifies a capable hand, but does not establish suitability for every manipulation task. Application selection still requires attention to the specific mechanical and control requirements of the intended robotic system.
The Linker Hand L6 is listed as in production, with an advertised price of USD 2,800 and an option to inquire about pricing. LinkerBot is based in China, and its manufacturer website is www.linkerbot.cn. For prospective buyers, production status and a published price provide useful starting points for procurement discussions, separate from the hand’s technical ratings. Its broader significance lies in offering a robotic hand with a defined mechanical architecture and a balanced score across dexterity and strength. Evaluating it alongside alternatives requires keeping commercial information, physical specifications, and category ratings distinct. That separation supports a clearer comparison without treating an overall score as a substitute for application specific engineering assessment.