
Linker L30
$ 14 500
The Linker L30 is a high-dexterity, tendon-driven robotic hand with human-like motion, built for precise manipulation, flexible integration, and advanced robotics applications.
Showing 65–80 of 142 results
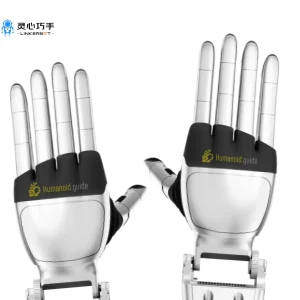
The Linker L30 is a high-dexterity, tendon-driven robotic hand with human-like motion, built for precise manipulation, flexible integration, and advanced robotics applications.
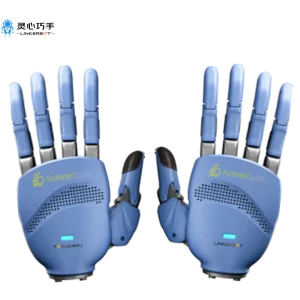
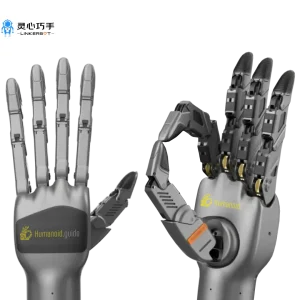
The Linker R30 is a high-dexterity robotic hand with human-like movement, designed for precise, adaptive manipulation in robotics, automation, and research applications.
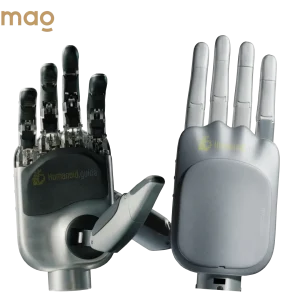
MagicHand H01 is MagicLab’s flagship five-finger dexterous hand with 20 DoF and 44 high-resolution 3D tactile sensors. It senses objects up to 40 mm before contact and responds quickly for safe, precise work in industry, service and care.
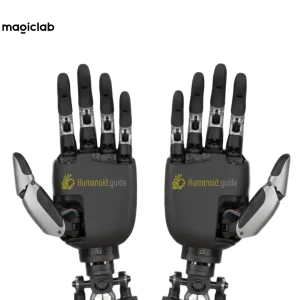

MagicHand S01 — a high‑precision 11‑DoF robotic hand by MagicLab, combining tactile sensing and hybrid control to deliver human‑like dexterity with up to 5 kg payload per hand (20 kg with a full robot), ideal for industrial, commercial, and service robotics.
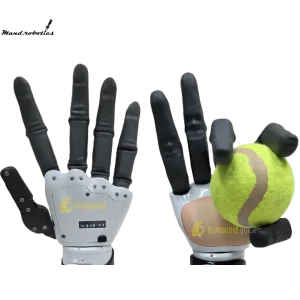

Mark 7 is a lightweight, human-sized robotic hand with 7 DoF and proprietary finger-integrated micro actuators. Its modular architecture allows customization of finger design, hand size, grip strength, speed, and finger length, making it suitable for human-like manipulation and tool use across a wide range of applications including prosthetic hands, robotics and automation.
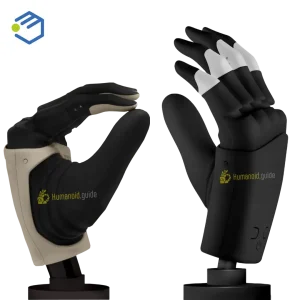

The Mia Hand Mk2 is a lightweight anthropomorphic robotic hand designed for humanoid robots, automation systems, and research platforms. It combines human-like grasping with a compact and robust design, allowing robots to manipulate tools and everyday objects efficiently.
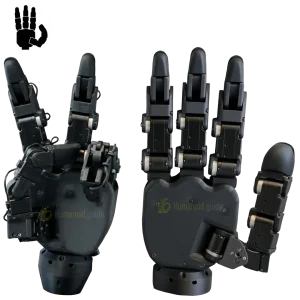
MIDAS Hand is an open-source, four-finger tactile dexterous hand for robot learning research. It offers 16 DoF (13 active), 283 three-axis taxels and direct-drive Dynamixel motors, buildable for about $3,000 in under three hours.
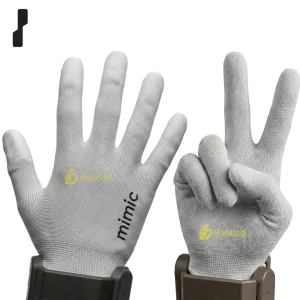
The mimic hand M1 is a Swiss-made, tendon-driven robotic hand purpose-built for industrial automation. It pairs human-like dexterity with serious strength, lifting payloads over 25 kg while sensing forces as light as 50 g. Built-in force sensing, fingertip touch, and a wrist camera make it a smart, durable end-effector for AI-driven manipulation.
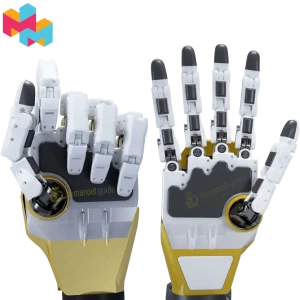
MM-Hand 1.0 is HKU MMLab’s open-source, remote tendon-driven dexterous hand with 21 fully actuated DoF. The ~350 g hand carries tactile sensors, joint angle sensors and palm cameras, with about $1,400 in material cost.
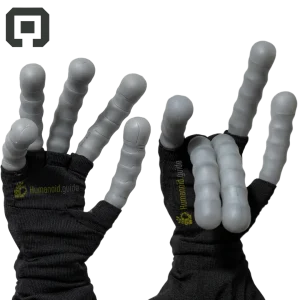
Muscle V0 is Daxo Robotics’ ultra-redundant dexterous hand, built with 120 individual tendon-driven actuators — reportedly the most actuated robotic hand yet made. With no rigid joints, real-time force-aware touch, and a fully backdrivable, sensor-ready design, it’s built for developers and researchers who need dexterity beyond typical humanoid hands. It’s heading toward a limited release in Fall 2026.
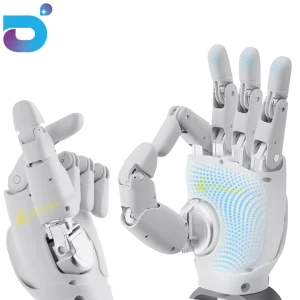
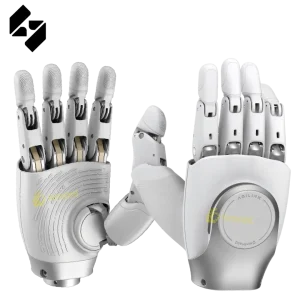
OmniHand 3 is AGILINK’s standard-tier dexterous hand — 510g, 16 degrees of freedom, and over 300 distributed tactile sensing points across the fingertips, palm, and back of the hand. Positioned as the company’s volume-deployment model, it’s already active across humanoid platforms, mobile manipulators, and research labs.
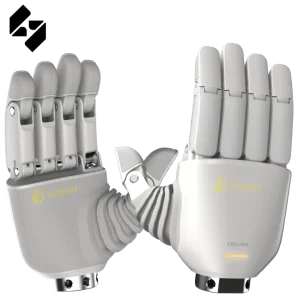
OmniHand 3 Lite is Agilink AI’s compact, 350g dexterous hand — roughly the size of a computer mouse — built for half-scale humanoids and mobile manipulators. With 11 total degrees of freedom, a rugged metal-and-silicone build, and an open developer toolkit, it brings real manipulation to small robotic platforms at an accessible price.
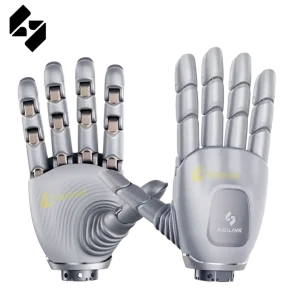
OmniHand 3 Ultra-M is AGILINK’s flagship direct-driven dexterous hand — a 630g, 20-DoF, human-scale hand built for embodied AI training and research. With encoder-level ground-truth data, vision-based fingertip tactile sensing, and 300-point palm sensing, it’s engineered for continuous-duty, contact-rich manipulation work.
Select at least 2 products
to compare


