NVIDIA GR00T N1
$ 0
Open foundation model for humanoid robots with dual-system VLA architecture
Showing 65–80 of 96 results
Open-source 7B VLA trained on Open X-Embodiment dataset; widely adopted open baseline for robot manipulation
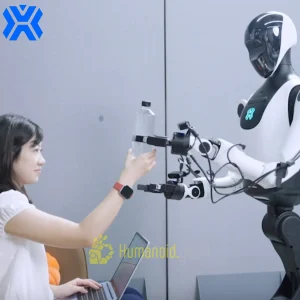
Pelican-Unify 1.0 is X-Humanoid’s unified embodied AI model. It combines understanding, reasoning, imagination and action in one model, so robots can predict outcomes and act on them.
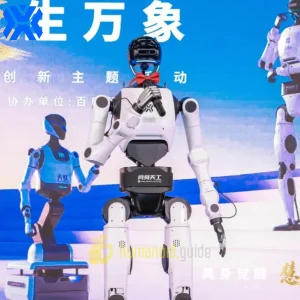
Pelican-VL 2.0 is X-Humanoid’s embodied AI brain model. It helps robots understand scenes, plan long tasks and use tools, and it works with motion controllers such as those in Tiangong humanoids.
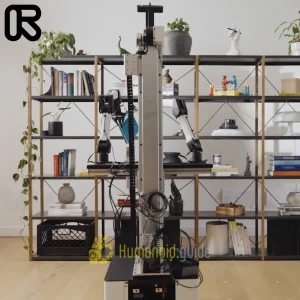
Praxis-1 is Runway’s first robot foundation model. It learns mainly from video and is designed to run on many robot types, with an open-weight release planned.
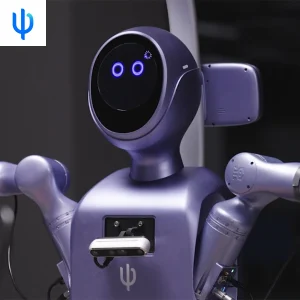

Psi R1 is a Vision-Language-Action (VLA) model by PsiBot that enables robots to perform complex, long-horizon tasks through integrated perception, reasoning, and action.
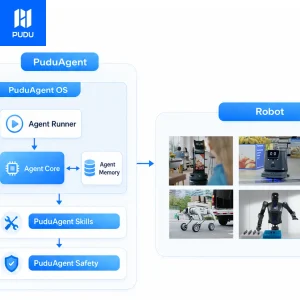

PuduAgent is Pudu Robotics’ general-purpose embodied agent platform, built on the PuduFM foundation model. It gives developers a unified software layer — system, capability, and safety — so many different robot forms can share one intelligence.
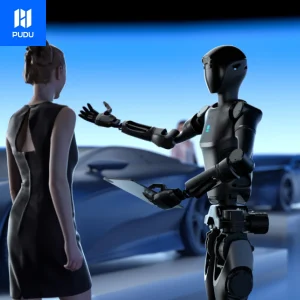
PuduFM 1.0 is Pudu Robotics’ embodied-intelligence foundation model built around physical intuition. It unites navigation and manipulation in one brain, learns from a massive real-world data flywheel, and powers many robot types under a “One Brain, Multiple Embodiments” approach.
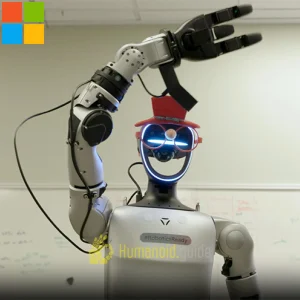
Rho-alpha is Microsoft Research’s first robotics foundation model. It combines vision, language and touch so robots can handle objects with two hands and learn from human feedback.

Proprietary predictive world model for autonomous robot decision-making; anticipates consequences of robot actions

RLDX-1 is a robotics foundation model from RLWRLD that specializes in dexterous robotic manipulation and humanoid interaction. The model combines visual understanding, language processing, tactile sensing, and force feedback to help robots perform complex real-world tasks with high precision.
Alibaba DAMO Academy’s open embodied brain model that helps robots understand scenes, remember where things are and plan tasks step by step.
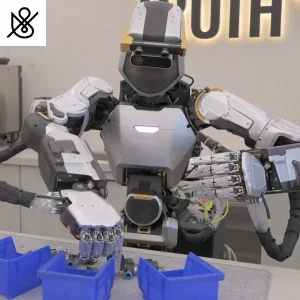

Proprietary full-stack AI for Phoenix humanoid; not a separable foundation model
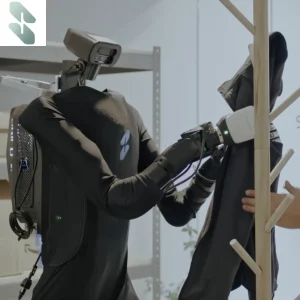

Omni-bodied foundation model across quadrupeds, humanoids, arms and mobile manipulators; hierarchical architecture


