Cosmos 3
$ 0
Cosmos 3 is NVIDIA’s open world model for physical AI. It understands scenes, generates future video and predicts actions, helping teams train and test robots faster.
Showing 17–32 of 96 results
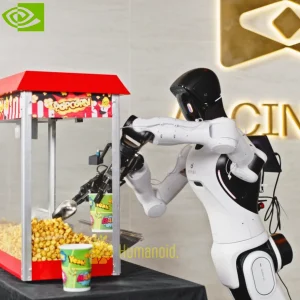
Cosmos 3 is NVIDIA’s open world model for physical AI. It understands scenes, generates future video and predicts actions, helping teams train and test robots faster.
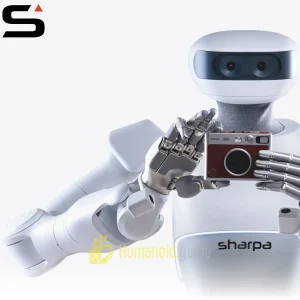
CraftNet is Sharpa’s AI model for dexterous robot hands. It combines vision, touch and language so robot hands can handle delicate tasks such as buttoning a shirt or turning a key.

Model-based RL agent that learns directly from image observations on real robots with a world model; no sim-to-real needed

NVIDIA world model for robot training via simulation; integrated with Isaac and GR00T ecosystem
DreamZero is an open world action model from NVIDIA’s GEAR Lab. It predicts video and robot actions together, which helps robots handle new tasks and places without extra training.
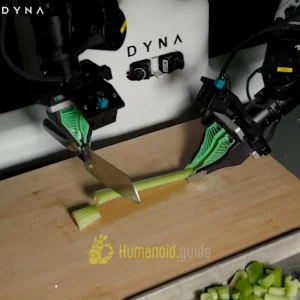
DYNA-2 is Dyna Robotics’ world-action model, trained on over a million hours of human video. It powers the company’s commercial robots with better reliability at new sites.
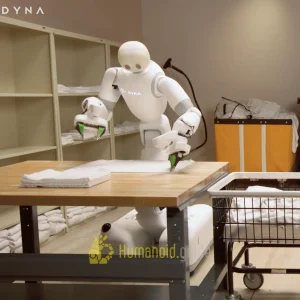
Dyna-2.1 is DYNA Robotics’ full-stack AI system for its Taku robot. It combines body control, hands-on skills and task planning to run hour-long workflows such as hotel laundry.
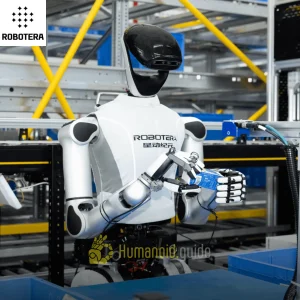

ERA-42 is RobotEra’s onboard AI model that gives its humanoid robots the ability to see, understand language, feel through touch, and move their whole body as one connected system. It powers real-time, dexterous tasks like tool use and object handling across the company’s robot lineup.
Fast-WAM is an open world action model from Tsinghua University and Galaxea AI. It learns from video during training but skips imagining the future when acting, so it reacts faster.

World model-based autonomy platform for robots in unstructured environments; focuses on outdoor and industrial settings
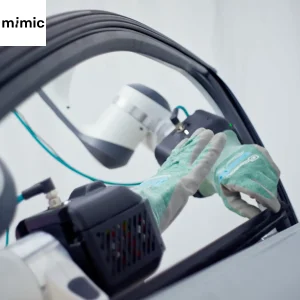
FLUX-mimic is a Video-Action Model from Swiss company mimic robotics, built with Black Forest Labs on their FLUX 3 video backbone. It gives robots general-purpose dexterity for complex factory manipulation, and runs on the robot itself rather than in a datacenter.
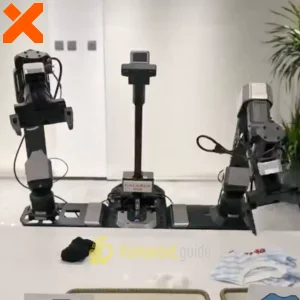
G0.5 is Galaxea’s robot foundation model that thinks and acts in one stream. It runs on many robot types and follows new instructions without extra training.
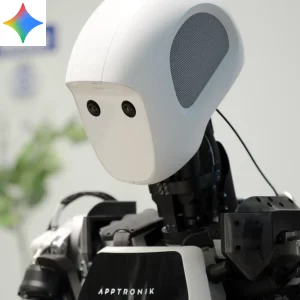

Gemini Robotics 1 extends multimodal capabilities for dexterous tasks like origami folding
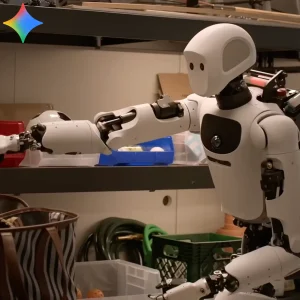
Gemini Robotics 2 is Google DeepMind’s foundation model for robots. It lets a machine understand a spoken request, plan the steps, and carry them out — whether it walks on two legs or works from a fixed base.
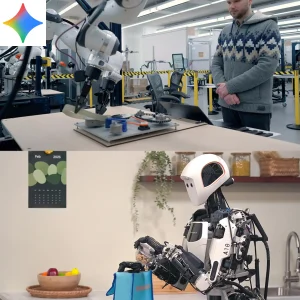
Built on Gemini 2.0; extends multimodal capabilities for dexterous tasks like origami folding
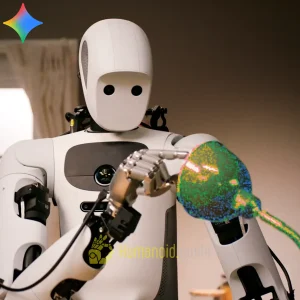
Gemini Robotics-ER 2 is Google DeepMind’s planning brain for robots. It watches tasks unfold, plans long jobs, calls tools and action models, and helps different robots work together.


