Meta open sources Project SuperDex for robot dexterity
Project SuperDex combines contact focused simulation, headset teleoperation and data generation, with a claimed zero shot transfer to a real robotic hand.
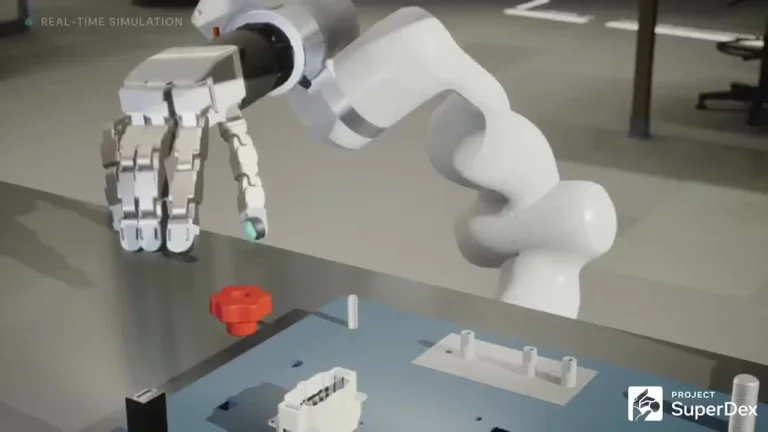
Project SuperDex combines contact focused simulation, headset teleoperation and data generation, with a claimed zero shot transfer to a real robotic hand.
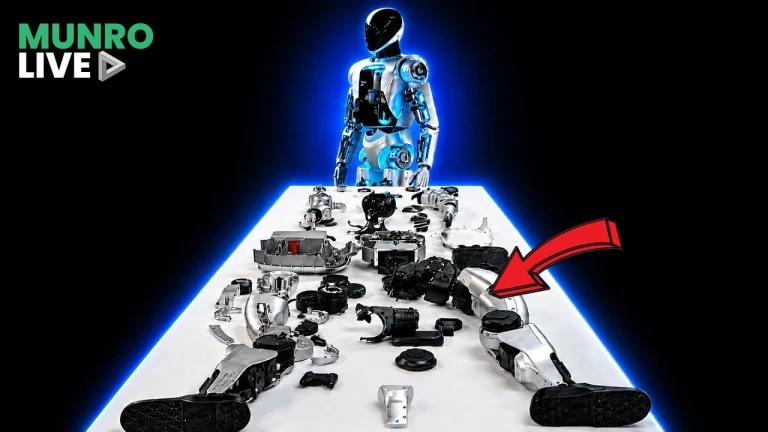
Munro Live’s full teardown of the Unitree G1 shows planetary actuators, unusual heat pipe cooling, extensive CNC machining and production compromises.
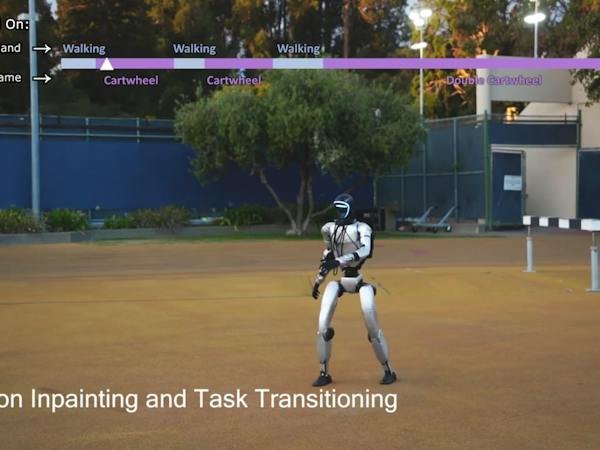
BeyondMimic used 2.5 hours of human motion data to train a Unitree G1, then transferred 30 representative motions to hardware without task specific tuning.
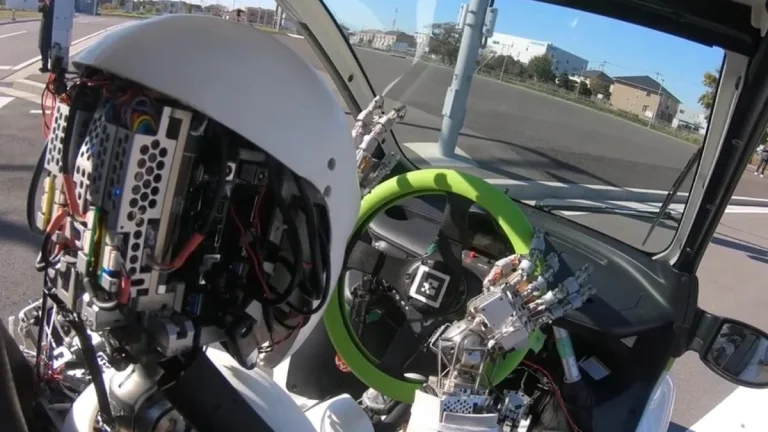
University of Tokyo’s Musashi humanoid operated a regular car’s controls and recognized traffic signals, although its early speed was limited to 3 mph.
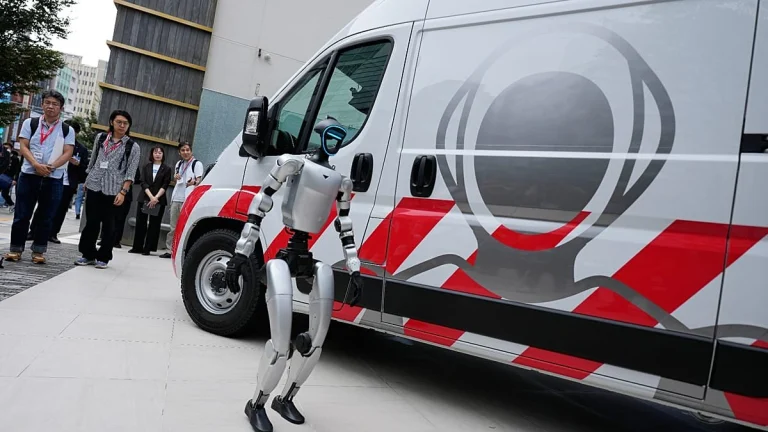
GMO Air’s mobile workshop carries engineers, repair gear and a spare humanoid, letting operators replace damaged robots while repairs continue off site.
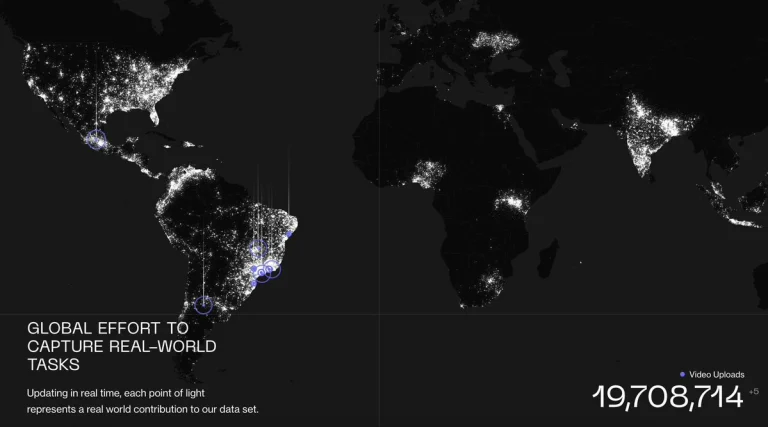
Figure says 86,000 weekly active users are uploading data to its robotics dataset, with a live map visualizing contributions around the world.

JoyIn says its Aether control model cuts humanoid training time and improves first attempt task success, but its OpenAI allegations remain unverified.

NVIDIA’s SONIC controller learned from more than 100 million human motion frames and accepts VR, video and language based commands without retraining.

X-Humanoid is prioritizing reliability and practical tasks after its 75 kg Tiangong Ultra humanoid completed a 100 meter sprint in 8.64 seconds.

Hexagon Robotics’ AEON has entered Schaeffler’s German Humanoid Gym for task training and validation ahead of planned global factory deployments.


