Welcome, Sanctuary AI’s Hydraulic Hand!
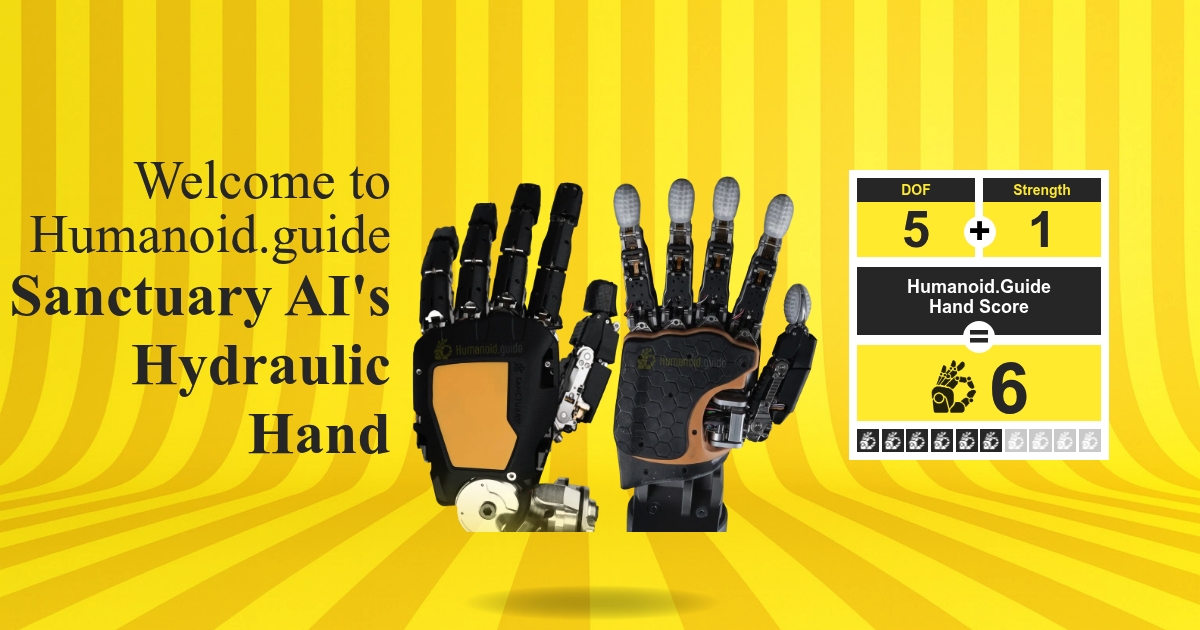
Sanctuary AI’s Hydraulic Hand is a human scale robotic end effector designed for industrial automation and future humanoid systems. Developed by Sanctuary AI in Vancouver, Canada, it uses miniaturized hydraulic valves and actuators rather than conventional electric motors or tendon driven mechanisms. This compact hydraulic architecture is intended to combine controlled motion, efficient load holding, and reduced heat generation within a hand sized form factor. The hand receives a Humanoid.Guide Hand Score of 6 out of 10, placing it in the capable or mature category. Its degrees of freedom rating is 5 out of 5, indicating a highly rated dexterity configuration, while its strength rating is 1 out of 5. Sanctuary positions the design for precise industrial handling where compact dimensions, controlled force, and reliable operation are important. The product is listed at 15 000 USD and is presented as a specialized hardware platform for advanced robotics development, factory pilots, and integration with robotic arms.
The hand’s core technical approach centers on low pressure hydraulic actuation delivered through miniaturized valves. Hydraulic actuation offers a distinct alternative to motor driven hand architectures, particularly where compact packaging and energy efficient load retention matter. Its top tier degrees of freedom rating emphasizes dexterity as the defining element of the design, while the lower strength tier indicates that the hand is not positioned primarily as a maximum force gripping solution. This balance makes it relevant to industrial settings involving controlled handling of components, tools, and manufactured goods. The system is intended for deployment on robot arms and eventual humanoid platforms, supporting a hardware direction focused on more capable manipulation systems rather than simple open and close grippers.
Availability is listed as prototype, placing the Hydraulic Hand in an active development and pilot preparation stage. Sanctuary AI has developed robotic dexterity technology since 2018 and is preparing this hand for industrial pilot programs. Its significance lies in demonstrating a different actuation path for advanced robotic hands, using compact hydraulics in a format associated more often with electric motors, cables, or tendons. The design reflects growing demand for end effectors that can support sophisticated industrial automation while fitting within human scale robotic systems. For manufacturers and robotics integrators, it represents an early commercial option for evaluating hydraulic hand technology in applications where dexterity is a higher priority than top tier grip strength.