Welcome, Tacta Hand!
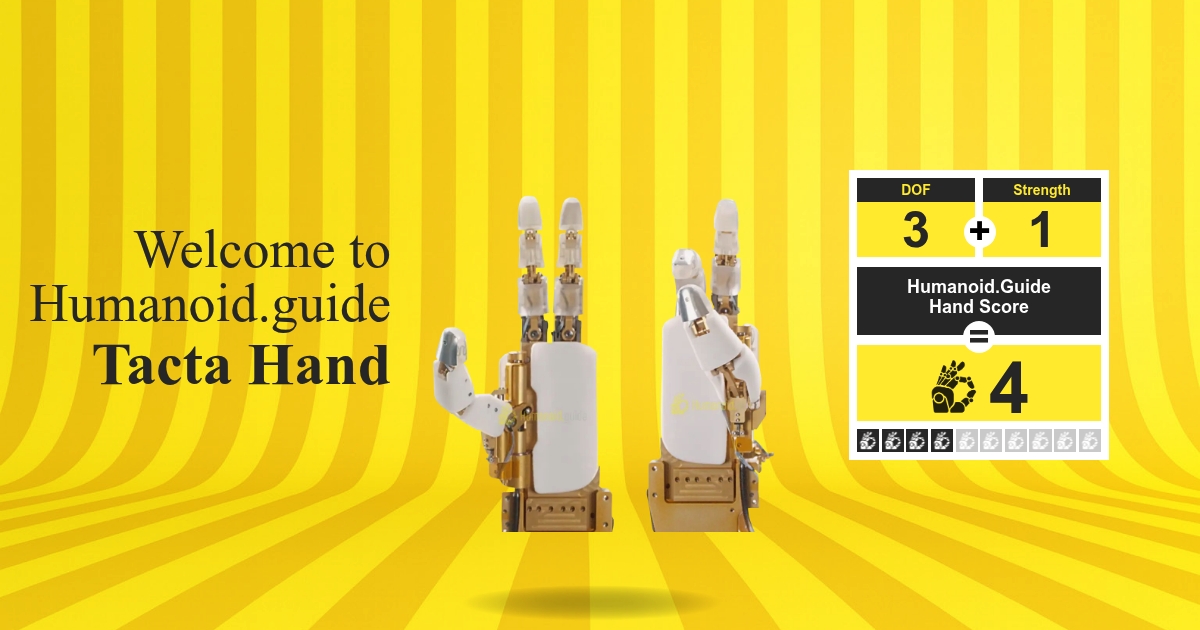
Tacta Hand is a human scale robotic hand from Tacta Systems Inc., built around tactile interaction and worker informed training. Its five finger form uses proprietary Fluidic Tendon actuation, an internal fluid driven cable and piston architecture that drives finger motion without bulky motors in the fingers. A lightweight metal and composite housing contains the system, and the hand weighs 0.55 kilograms. Tacta Hand incorporates ultra miniature tactile sensing hardware, with sensors described as smaller than a grain of sand. The sensor specification lists a contact force range from 250 to 700,000 pascals and a sampling rate of 400 times per second. Tacta pairs the hand with a skill capture glove for recording task demonstrations by workers and connecting those demonstrations to robot training. The hand earns a Humanoid.Guide score of 4 out of 10, placing it in the developing category. Its degrees of freedom rating is 3 out of 5, while its strength rating is 1 out of 5. This scoring emphasizes a developing dexterity profile alongside a lower strength tier.
The technical configuration combines proprietary tactile sensor hardware, Fluidic Tendon actuation, and a skill capture glove. The tactile sensor specification gives a contact force range of 250 to 700,000 pascals and a sampling rate of 400 times per second. The actuation design is described as fluid moving through internal cables and small pistons, with the components located within the hand structure. The glove is part of the product training setup and records demonstrations performed by workers. For evaluation context, the hand has a 3 out of 5 degrees of freedom rating and a 1 out of 5 strength rating. These tier scores are qualitative benchmarks and should not be read as literal mechanical counts or force values. Together, the architecture and scoring identify the principal technical attributes used to assess the platform.
Tacta Hand is listed as in production and has a displayed price of 20,000 USD. Tacta Systems Inc. is a US manufacturer founded by veteran entrepreneurs in Palo Alto, California. The product contributes to a broader effort to combine robotic hand mechanics, tactile information, and human demonstration collection within one system. Its skill capture approach connects experienced workers with robot training workflows, creating a direct path for documenting manual task knowledge. This is significant for manufacturers evaluating robotic hands as part of larger automation programs, especially where actuation design and training methods matter alongside hand scoring. The developing 4 out of 10 overall score frames Tacta Hand as an in production platform whose evaluation should consider both its middle tier degrees of freedom rating and lower strength tier rating.