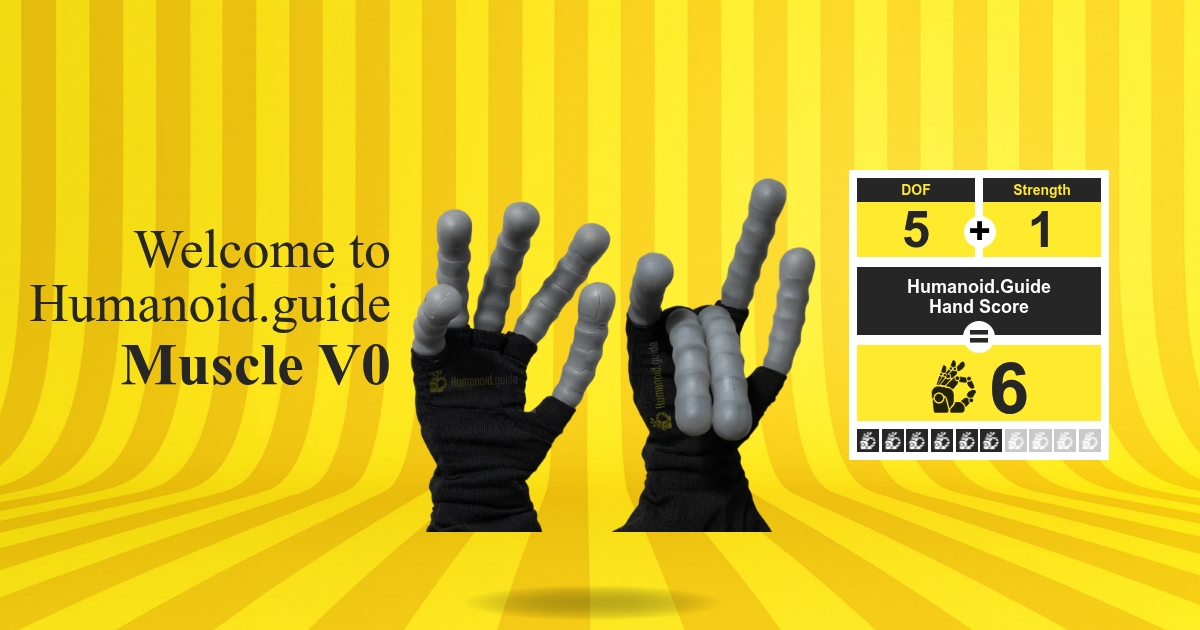
Welcome, Muscle V0!
Muscle V0 is a dexterous robotic hand from Daxo Robotics, engineered around an ultra redundant tendon driven architecture with 120 individual actuators. Its compliant structure contains no rigid joints, using flexible materials and tendon routing to create a hand designed for intricate physical interaction. The product earns a Humanoid.Guide Hand Score of 6, placing it in the capable and mature range. It is rated 5 out of 5 for degrees of freedom, emphasizing sophisticated finger articulation and mechanical versatility, while its strength rating is in a lower tier. Daxo Robotics designed Muscle V0 for developers and researchers seeking a highly articulated hand platform rather than a conventional rigid gripper. The distributed actuator design avoids dependence on a single motor, supporting continued operation when individual actuators are unavailable. At 0.75 kg, the hand combines a lightweight form with a five finger layout intended for experimental robotics, advanced manipulation research, and detailed studies of compliant hand mechanics.
The hand’s 5 out of 5 degrees of freedom rating highlights its emphasis on dexterity and nuanced finger motion. Its tendon based construction distributes motion across 120 small motors, giving researchers a distinctive platform for studying actuator coordination, compliant mechanics, and control approaches for multi fingered hands. Muscle V0 is particularly relevant for laboratory work involving object handling research, tactile interaction experiments, and the development of control software for highly articulated end effectors. The lower strength tier establishes a clear design priority: precise, adaptable interaction takes precedence over high force handling. With no rigid joint framework, the hand offers an alternative to traditional metal linked robotic hands and supports investigation into soft robotic design principles, redundancy, and resilient actuator systems.
Muscle V0 is currently a prototype, with Daxo Robotics preparing a limited release for Fall 2026. The company has tested the design through more than 100,000 actuation cycles and continues durability testing ahead of release. Its arrival is significant for robotics teams that need access to an unusually actuator dense hand design for research and development. Rather than following the common approach of using a small number of powerful motors, Daxo Robotics has built a platform centered on redundancy, compliance, and detailed control. This direction broadens the range of hardware available to universities, robotics laboratories, and developers working on advanced hand systems. The planned limited release positions Muscle V0 as an early access research tool for teams prepared to explore specialized hardware architectures.