Welcome, Jingchu Elf!
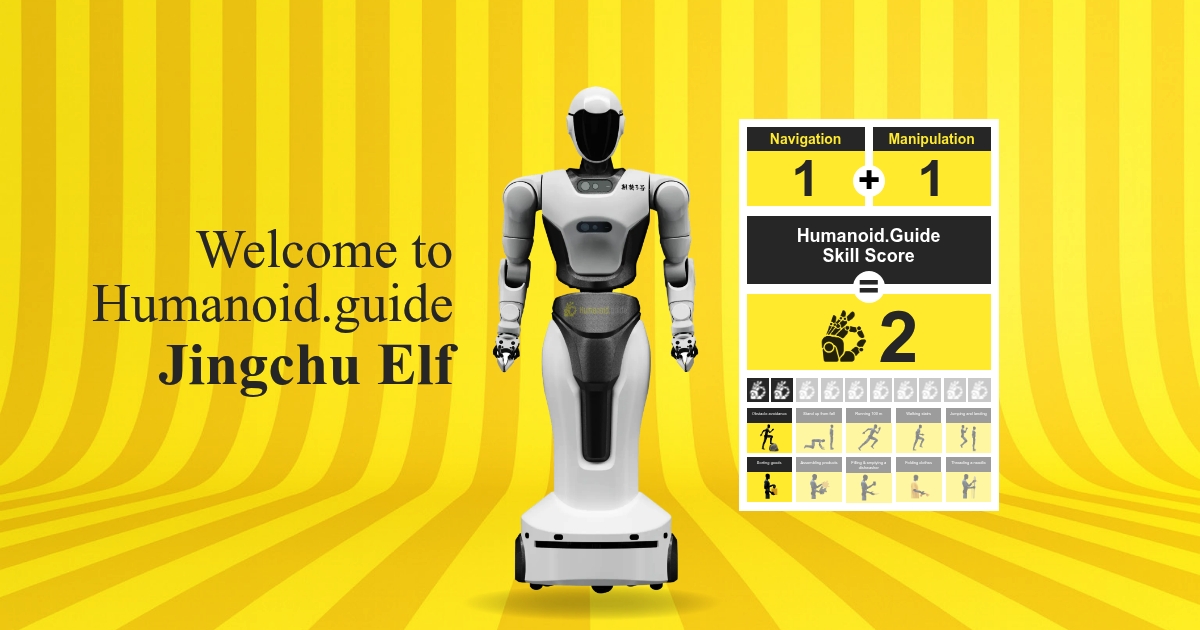
Jingchu Elf is a wheeled service humanoid developed by Hubei Jingchu Humanoid Robot Co., Ltd., a Wuhan robotics company operating under the JCBOT brand. Standing 165 cm tall and weighing 70 kg, it combines a humanoid upper body with a base driven by two wheels rather than legs. Its body has 16 degrees of freedom, and its hands have five fingers each. Listed specifications include a maximum speed of 3 km/h, a strength rating of 4 kg, and approximately eight hours of operation per charge. LiDAR, depth sensing, and SLAM navigation support obstacle avoidance, while sorting goods is another demonstrated capability. Computing hardware includes an NVIDIA Ampere GPU with 1,024 cores and 32 Tensor Cores, delivering approximately 117 TOPS. External computing is also supported. Its overall skill score of 2 out of 10 places it at an early stage, with Navigation and Manipulation each rated 1 out of 5. Intended markets include research, development, reception, public service, and exhibition halls.
Obstacle avoidance and sorting goods define Jingchu Elf’s current physical capability profile. For mobility, its wheeled base works with LiDAR and a depth camera to support autonomous navigation around obstacles. Its maximum speed of 3 km/h suits a measured pace in indoor service environments. For manipulation, sorting goods provides a concrete task around which developers can structure evaluations and application trials. High torque rotary joint modules and planetary reducers form part of its motion hardware, while the humanoid upper body supplies the physical platform for object handling. The Navigation and Manipulation ratings remain in the lower tier, so these capabilities should be understood as preliminary rather than evidence of advanced autonomy or broad manipulation proficiency.
Jingchu Elf is listed as a prototype with a price of USD 25,000. That status makes it most relevant to organizations evaluating humanoid platforms for research, development, and exploratory service applications. Within JCBOT’s lineup, it is the wheeled companion to the walking Jingchu No.1, offering a different physical architecture for service settings. Its combination of an adult sized body, onboard NVIDIA computing, WiFi 6 connectivity, and approximately eight hours of runtime gives prospective users several practical specifications to assess alongside its early capability ratings. Its broader significance lies in bringing humanoid manipulation and wheeled navigation into one development platform, with obstacle avoidance and sorting goods serving as concrete starting points for evaluation rather than a claim of comprehensive workplace readiness.