ETH Zurich team demonstrates Unitree G1 climbing and crawling
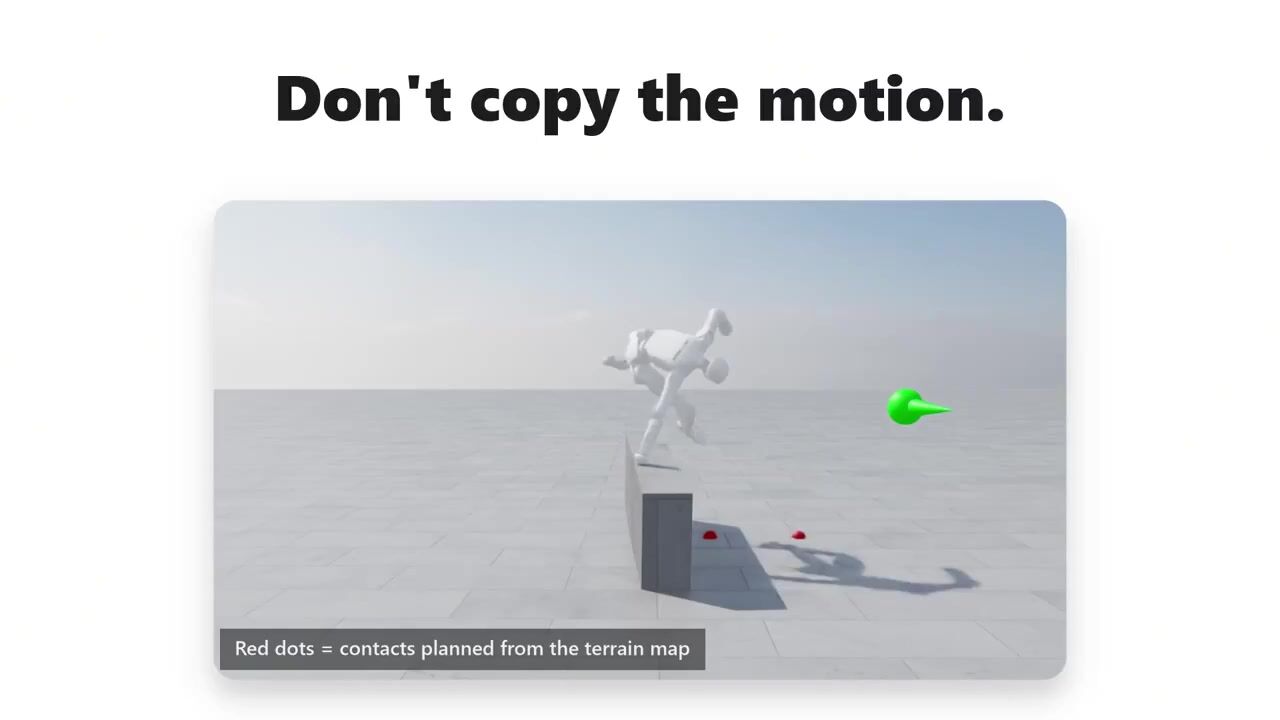
An ETH Zurich team has developed a single policy for a Unitree G1 to walk, climb and crawl, according to a post on X by RoboHub (@XRoboHub). The account says transitions between those movements are not manually scripted. Its description points to a locomotion approach that coordinates different forms of movement rather than relying on explicitly programmed transitions between them.
According to the post, the team trained ACP using 13.2 minutes of human motion data to learn contact patterns, then used reinforcement learning in simulation to adapt to new terrain. The human demonstrations supply contact patterns for training, while the reinforcement learning stage addresses terrain adaptation. At runtime, onboard sensing and a goal guide the placement of the robot’s hands, feet and knees, without a reference motion to follow.
The Unitree G1 climbing example includes a ladder recovery sequence that, according to RoboHub’s account of the team’s claim, was not explicitly included in the human demonstrations. That is the most specific example in the post of behavior beyond the demonstrated motions: the reported recovery uses the learned policy rather than an explicitly demonstrated recovery sequence.
View the original post on X
Source: @XRoboHub on X