Welcome, OmniHand 3 Lite!
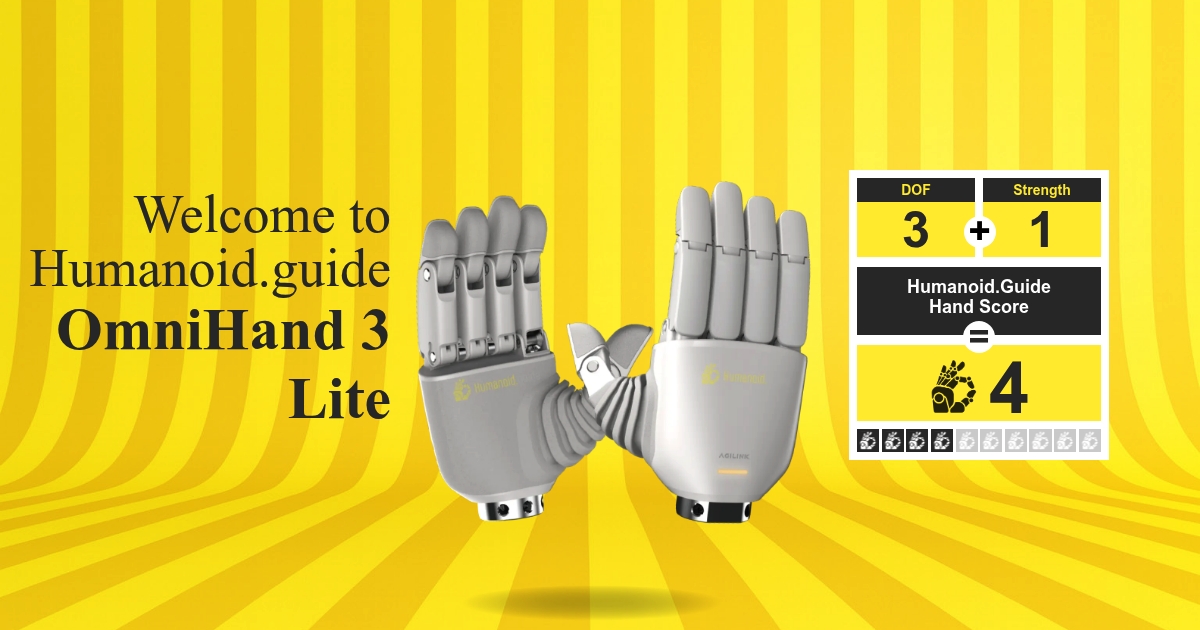
OmniHand 3 Lite is a compact robotic hand from AGILINK designed for half scale humanoids, mobile manipulators, and other small robotic platforms. Weighing 0.35 kg and measuring 140 × 70 × 32 mm, it brings hand like manipulation to robots that need a lightweight alternative to larger dexterous end effectors. Its overall Humanoid.Guide Hand Score of 4 places it in the developing category, with a 3 out of 5 rating for degrees of freedom and a 1 out of 5 rating for strength. The hand uses compact tendon and servo driven actuation within an aerospace grade metal frame, protected by a one piece silicone overmold. This construction prioritizes resilience during drops, impacts, and repeated contact in practical robotics environments. Five fingers support adaptable object handling, while the compact form factor helps designers preserve payload capacity and arm mobility. OmniHand 3 Lite targets accessible dexterity for compact systems rather than maximum force output.
The hand is designed to close around irregular objects through a combination of active and passive motion, allowing the fingers to conform naturally during grasping. Its approximately half second opening and closing action supports responsive pick and place work, sorting, handling household objects, and lightweight research tasks. The metal internal structure and silicone exterior provide a balance between durability, protection, and compliant contact with handled items. Developers can use the open source toolkit to integrate controls, adapt grasp behaviors, and connect the hand to experimental manipulation systems. An optional wrist mounted camera adds visual perception support for applications that benefit from basic object observation near the end effector. These features make the hand relevant for educational robotics, laboratory prototypes, compact service robots, and mobile platforms where space and mass are tightly constrained.
OmniHand 3 Lite is listed as in production, positioning it as an available component for teams moving from simple grippers toward more expressive robotic manipulation. AGILINK, formally Shanghai AGILINK Innovation Intelligent Technology Co., Ltd., is based in China and presents the product as a practical option for compact robot builders. Its significance lies in reducing the size and weight barrier often associated with multi finger robotic hands. Smaller humanoids and mobile manipulators can gain more versatile handling without requiring a large wrist, heavy arm, or high payload capacity. The accessible price point of 3,200 USD also supports experimentation by research groups, developers, and companies evaluating dexterous manipulation for smaller robotic systems.