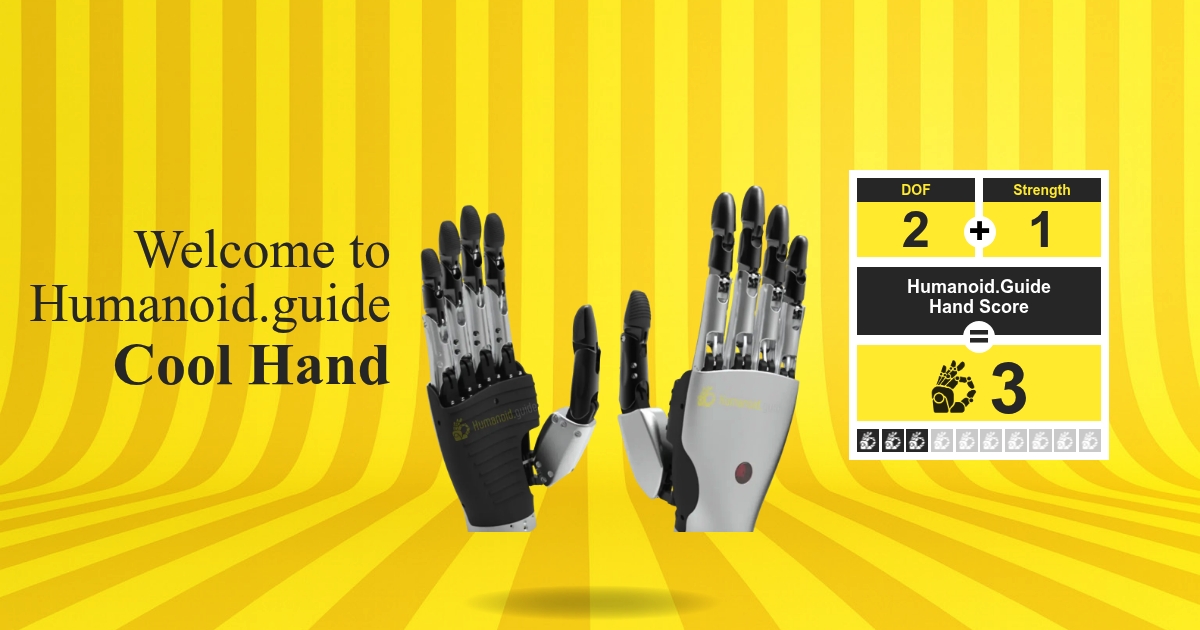
Welcome, Cool Hand!
Cool Hand is a compact robotic hand from Ti5ROBOT, designed for humanoid robotics, prosthetics, and research environments. The hand uses a five finger layout within a 205 by 132 by 80 mm form factor and weighs 0.48 kg, supporting integration where size and mass matter. Its engineering grade aluminum alloy frame is paired with a polymer and composite outer housing, combining structural rigidity with a more refined external finish. Cool Hand receives a Humanoid.Guide Hand Score of 3 out of 10, placing it in the developing category. Its degrees of freedom rating is 2 out of 5, while its strength rating is 1 out of 5. This positioning emphasizes a design focused on accessible hand integration and development use rather than top tier force output or maximum dexterity ratings. Ti5ROBOT presents Cool Hand as a bionic mechanism intended to bring more natural finger and thumb movement into robotic hand systems.
The hand incorporates six internal electric actuator units and proprietary motion sensing control technology. Its mechanical configuration includes independently actuated fingers and a thumb designed for movement in two directions. Intelligent flexible torque control is intended to regulate applied force during operation, while tactile and force sensing are listed among the product specifications. These elements create a platform suited to engineering evaluation, manipulation research, prosthetic development, and humanoid hand integration. The product’s modest score profile highlights the importance of matching the hand to tasks that prioritize compact construction, sensor enabled control, and mechanical experimentation. Developers can assess the available ratings alongside factors such as mounting requirements, control interfaces, object handling goals, and the force demands of their intended application.
Cool Hand is listed as in production, making it relevant to teams seeking a currently manufactured robotic hand rather than a concept stage design. Ti5ROBOT is a Chinese robotics manufacturer, and the product contributes to the expanding ecosystem of specialized end effectors for humanoid systems and adjacent research fields. Its presence illustrates how hand development involves tradeoffs among actuator packaging, structural materials, sensing, weight, strength, and dexterity. With an overall score of 3, Cool Hand occupies a developing position within the broader hand market, offering a defined option for organizations comparing commercially available designs. Its technical direction also reflects continuing industry interest in bionic form factors and more responsive control systems for robotic manipulation platforms.