Welcome, Dual Arm Lift!
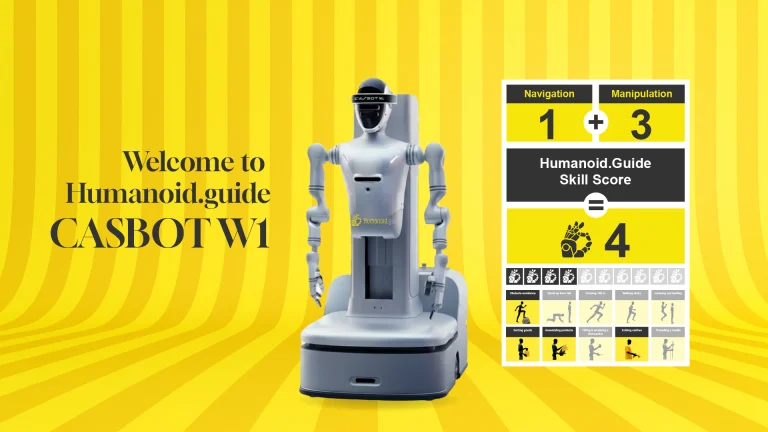
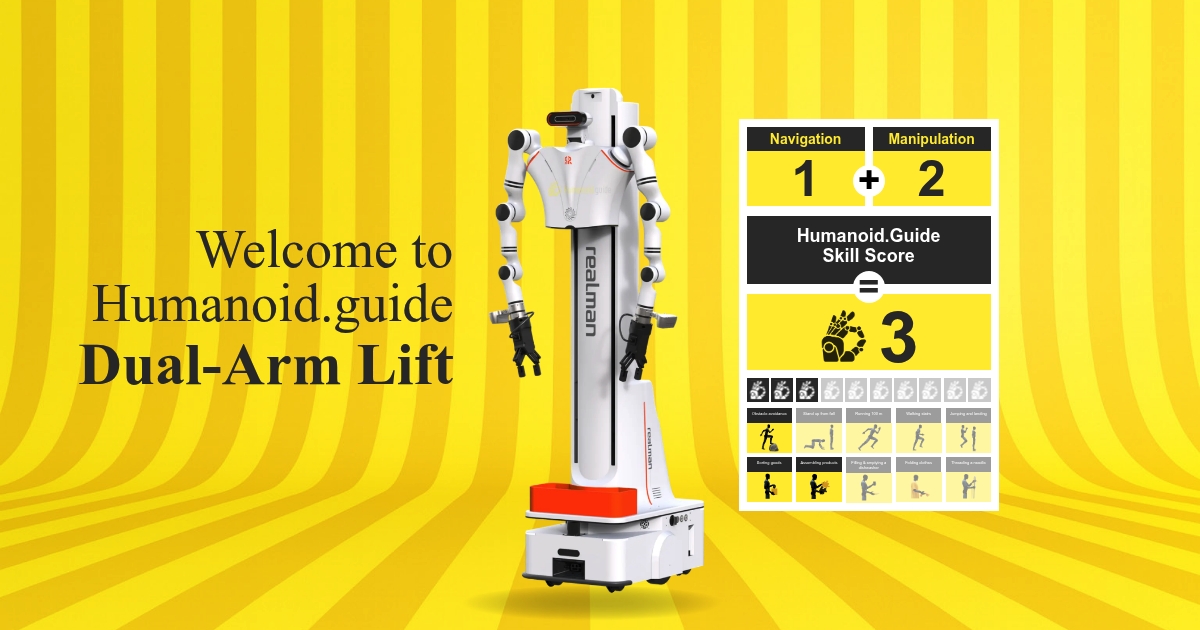
The RealMan Dual Arm Lift is a mobile manipulation platform that combines two coordinated robotic arms, a wheeled base, and an adjustable vertical lifting column. Built for industrial automation and robotics research, it brings mobility and variable working height into a single system. The robot stands 178 cm tall, weighs 157 kg, and has a listed strength specification of 10 kg. Its maximum travel speed is 3.6 km/h, with a stated runtime of four hours per charge. Two finger gripping claws provide the physical interface for handling objects, while an RGB depth camera system supplies visual and distance information. The arms can operate together or perform separate actions, supporting flexible arrangements around workstations and objects at different heights. Its overall Humanoid Guide skill score is 3 out of 10, placing it in the developing range. Navigation is rated 1 out of 5 and manipulation 2 out of 5, reflecting a platform whose manipulation rating is higher than its navigation rating.
Obstacle avoidance, sorting goods, and assembling products are the platform’s listed practical capabilities. Its wheeled base and lifting column provide a useful combination for arranging these activities across work areas with different working heights. Coordinated arms offer a configuration for assembly workflows, while the gripping claws support object handling during sorting. Linux and ROS compatibility give developers a familiar software environment for integrating these functions into experimental or industrial systems. Ethernet, RS485, USB, and Wi Fi connectivity provide several routes for connecting external equipment and development tools. External API integration also supports connections to language models through a separate developer workstation, extending the software integration options around the robot’s physical capabilities.
The Dual Arm Lift is in production through RealMan Robotics, a manufacturer based in China, and carries a listed price of USD 45,000. Its intended markets include industrial automation, mobile manipulation, embodied AI, research, and data collection. For organizations evaluating robotics platforms, its significance lies in combining a mobile base, two arms, and adjustable reach rather than specializing in a single fixed workstation format. This configuration provides a concrete platform for exploring sorting and assembly while developing the surrounding control software and workflows. Its developing skill score offers an important benchmark for setting expectations: the platform represents ongoing progress in mobile manipulation, rather than a claim of mature general purpose autonomy.