UniDex
$ 0
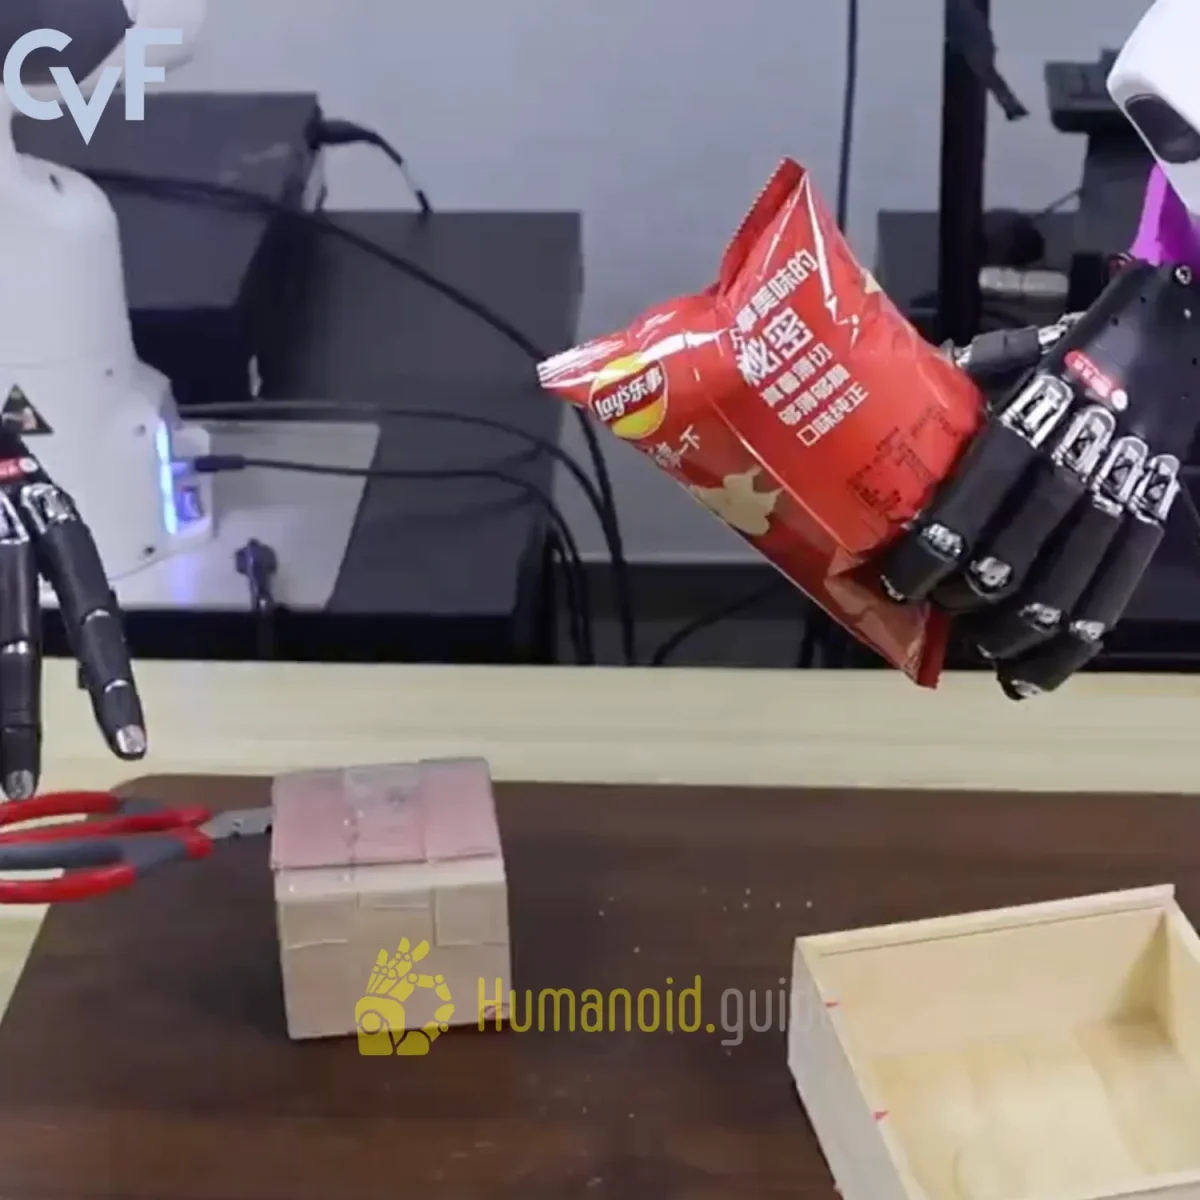
UniDex is an open foundation suite for dexterous robot hands from Tsinghua University. It lets one AI model control many different robot hands and learns largely from videos of human hands.
Available on backorder
Brain Score
 3


Specifications and details:
| Nationality | China |
|---|---|
| Website | https://iiis.tsinghua.edu.cn |
| Model type | Foundation Model |
| Manufacturer | Tsinghua University, IIIS |
| Release date | March 2026 |
Description
UniDex is a robot foundation suite for dexterous hands, led by Tsinghua University and the Shanghai Qi Zhi Institute. The team released it in March 2026 and presented it at the CVPR 2026 computer vision conference. Robot hands come in many designs, with different numbers of fingers and joints. As a result, a model trained on one hand usually fails on another. UniDex tackles this problem by giving all hands a shared way to describe their movements. In simple terms, it matches each joint’s role across hands, such as “bend the index finger.”
The suite has three main parts. First, a large dataset covers eight different robot hands. Next, the shared action format links those hands together. Finally, a vision-language-action model turns 3D vision and spoken instructions into hand movements. Notably, the team built much of the dataset from first-person videos of people using their hands. In tests, robot hands made coffee, swept, watered flowers and used a computer mouse. Moreover, a model trained on one hand worked on other hands without extra training. The team has also released the code and the model openly.
New! 2026 Humanoid
Robot Market Report
198 pages of exclusive insight from global robotics experts — uncover funding trends, technology challenges, leading manufacturers, supply chain shifts, and surveys and forecasts on future humanoid applications.
now Google DeepMind
Contact Humanoid.guide
Website: https://unidex-ai.github.io/