InternVLA-A1
$ 0
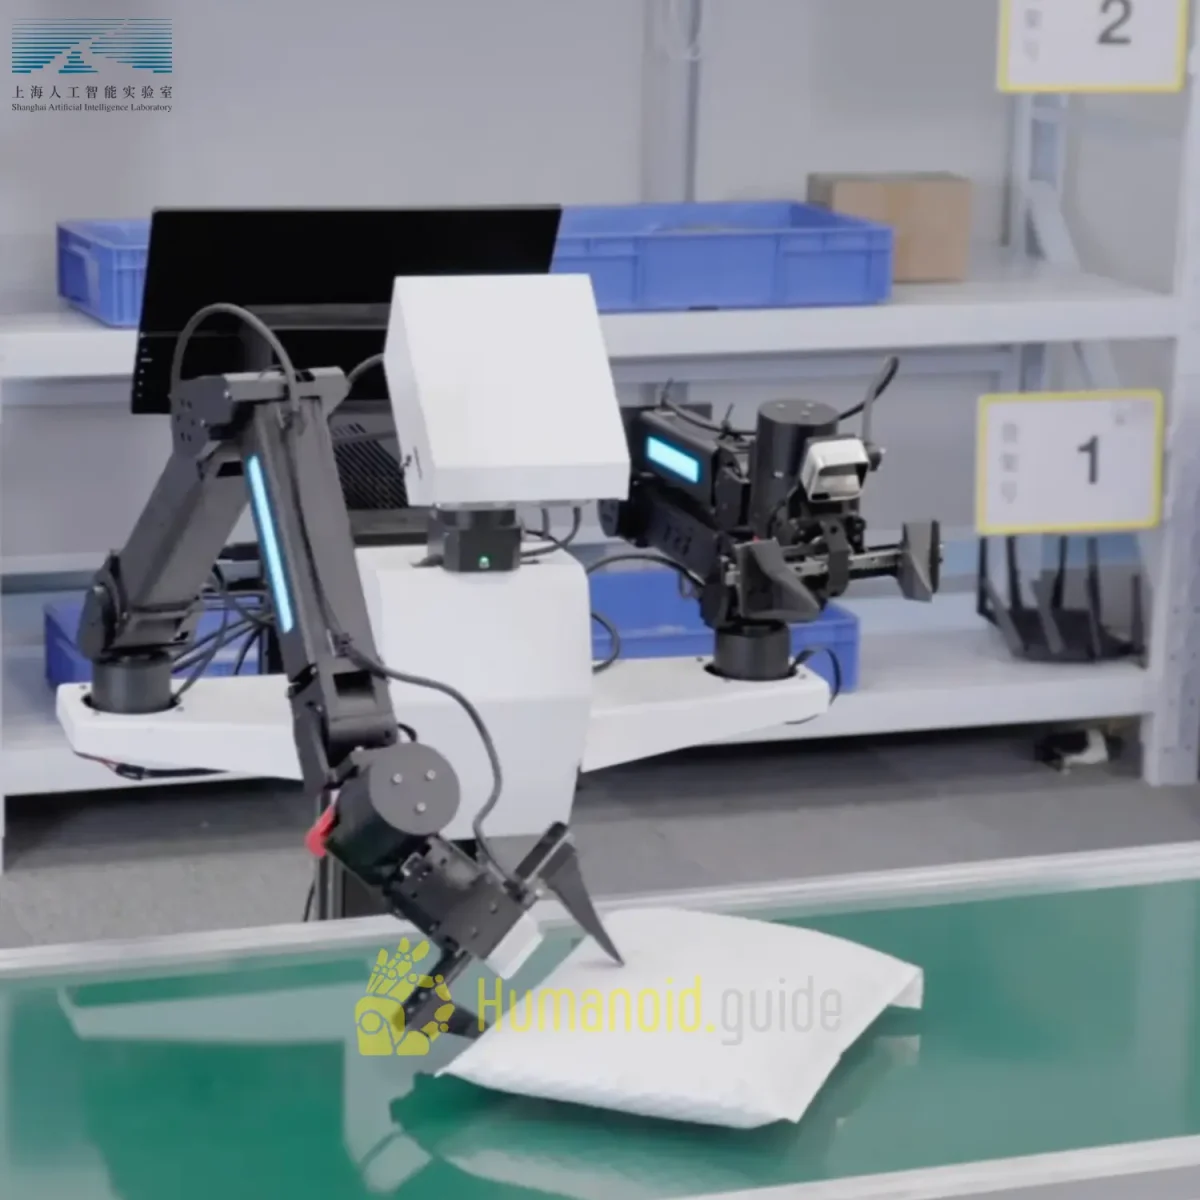
InternVLA-A1 is an open robot model from Shanghai AI Laboratory that understands scenes, imagines what happens next and then acts. It helps two-armed robots handle both still and moving objects.
Available on backorder
Brain Score
 4


Specifications and details:
| Nationality | China |
|---|---|
| Website | https://www.shlab.org.cn/ |
| Model type | Foundation Model |
| Manufacturer | Shanghai AI Laboratory |
| Release date | January 5, 2026 |
Description
InternVLA-A1 is a robot manipulation model from Shanghai AI Laboratory and its InternRobotics team. The lab released it in January 2026 with a paper, code and open checkpoints. It joins three skills in one network: it reads the scene, imagines what will happen next and then picks an action. Most VLA models understand scenes well but ignore physics, while video world models often miss the meaning of a task. So InternVLA-A1 tries to get the best of both. That idea makes it one of the clearest open examples of a VLA that also works as a world model.
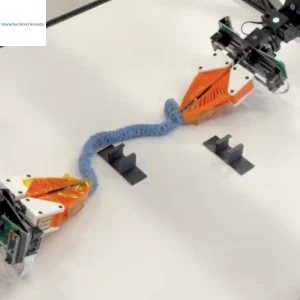
In practice, the model helps two-armed robots handle both still and moving objects. For example, it sorts parcels on a moving belt, picks food in motion, unscrews caps and zips bags. The team trained it on real robot data, simulation data and human videos, and it beat the pi0.5 baseline on dynamic tasks by a wide margin. It also runs at about 13 control steps per second on a single RTX 4090. Researchers can download the 3B model from Hugging Face under a non-commercial license. Meanwhile, it sits at the start of the lab’s InternVLA-A series, which later grew into InternVLA-A1.5.
New! 2026 Humanoid
Robot Market Report
198 pages of exclusive insight from global robotics experts — uncover funding trends, technology challenges, leading manufacturers, supply chain shifts, and surveys and forecasts on future humanoid applications.
now Google DeepMind
Contact Humanoid.guide
Website: https://internrobotics.github.io/internvla-a1.github.io/