NASA details Valkyrie’s role in lunar robotics testing
NASA’s Dexterous Robotics Team at Johnson Space Center is applying experience from the Valkyrie humanoid to robotic systems intended for lunar logistics, maintenance and scientific work. The 16 person group develops hardware and software for robots that can operate in environments built for people, with an emphasis on tasks normally performed with human hands.
According to NASA, the team combines mechatronics and software expertise, with many engineers working across electronics, mechanics, simulation and analysis. Its members include veterans of Robonaut 2, which participated in technology demonstrations aboard the International Space Station for seven years, and Valkyrie, described by NASA as its first bipedal humanoid robot.
“Our team is not trying to replace human explorers with robots but instead make human exploration safer and more sustainable by developing highly capable, reliable, and trustworthy robots to work in extreme environments.”Shaun Azimi, Dexterous Robotics Team lead
Valkyrie experience feeds current testing
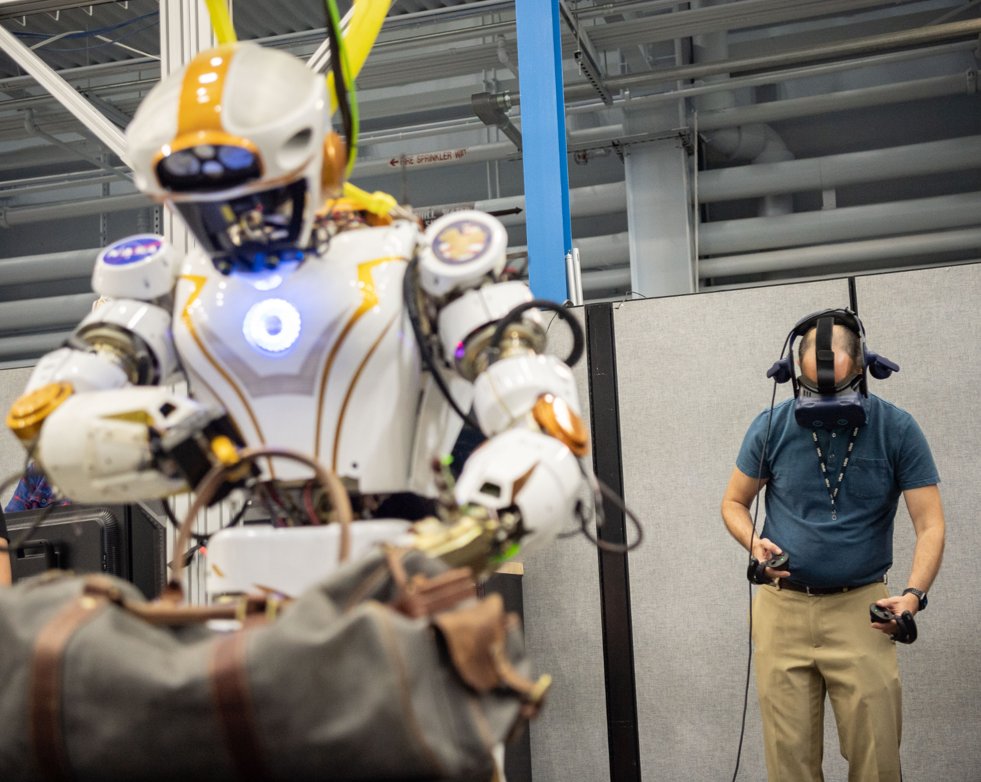
NASA continues to use Valkyrie in demonstrations, including teleoperated handling of a packed duffel bag. The agency’s account does not assign the humanoid to a flight mission or provide a deployment schedule. Instead, Valkyrie appears as part of a broader engineering program concerned with how robots perceive human spaces, manipulate familiar objects and work under human supervision.
The team is divided generally between mechatronics and software, although NASA says most members have experience spanning both physical systems and code. Some engineers also contribute to mobility projects within Johnson’s Robotic System Technology Branch.
The group supports NASA programs exploring technologies connected to a future Moon base and collaborates with external partners facing related problems in harsh environments. NASA cited work with an oil and gas company interested in using robotics for riskier tasks, although it did not identify the company or describe a specific deployment.
iMETRO provides a common test environment
A central part of the program is the Integrated Mobile Evaluation Testbed for Robotics Operations, or iMETRO. The Johnson facility combines open source software, simulation assets, spacecraft and habitat mockups, a selection of robots and an outdoor rock yard. Partners can test a complete robot or isolate individual hardware and software components.
The setup is designed around human supervised space exploration tasks, including cargo handling, maintenance and scientific research. It also lets habitat designers see where relatively modest changes, such as larger handles or better lighting, can improve robotic access while potentially helping astronauts as well.
NASA highlighted a test by PickNik in which software enabled a robotic arm to recognize a spacecraft hatch, turn its latch, grasp the handle and open the door. The arm then transferred cargo bags between the hatch and a bin. In another project, a NASA intern used a commercial robotic arm and camera to inspect and maintain a cold stowage freezer similar to units aboard the space station.
Those examples involve robotic arms rather than full humanoids, but they address manipulation and perception problems that Valkyrie class systems must also solve. NASA says the team’s near term work is focused on sustained lunar operations, with potential applications to later Mars missions.
Source: NASA