Welcome, OmniHand 3 Ultra M!
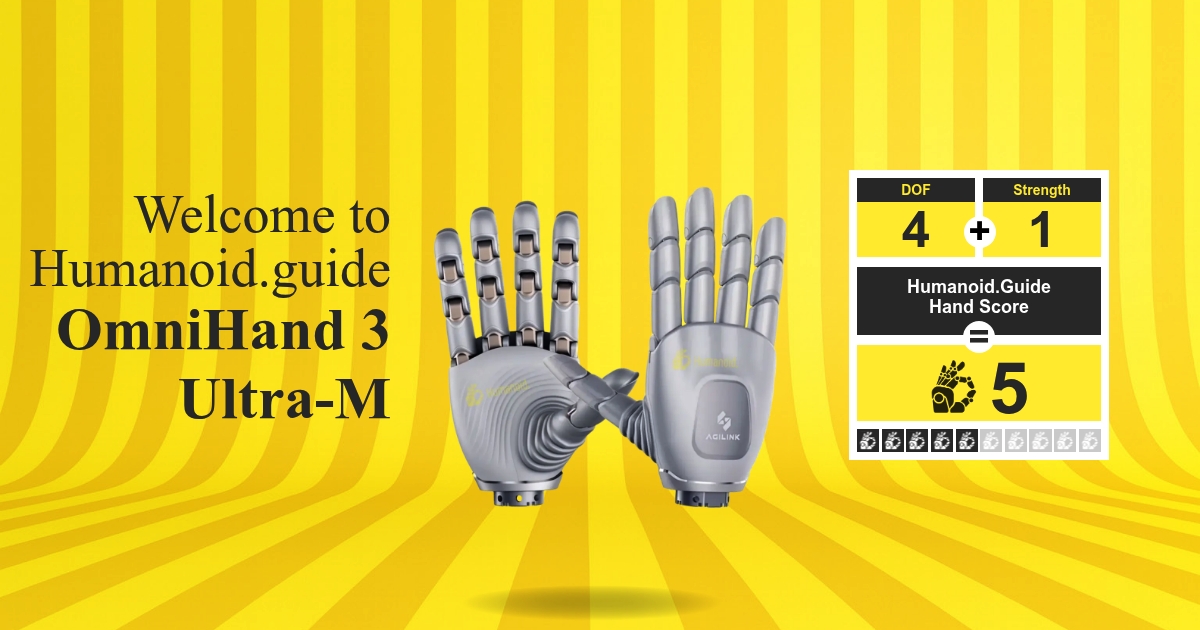
OmniHand 3 Ultra M is AGILINK’s flagship robotic hand for embodied AI training, teleoperation, and manipulation research. It combines a human scale form factor with direct drive actuation at each joint, eliminating tendon based transmission and supporting precise encoder derived joint positioning. The hand weighs 0.63 kg and measures 189.5 by 88.5 by 40 mm, using a lightweight alloy frame with engineering polymer covers. Its overall Humanoid.Guide Hand Score is 5 out of 10, placing it in the developing category. The hand receives a 4 out of 5 rating for degrees of freedom, indicating a strong dexterity tier, while its 1 out of 5 strength rating identifies grip force as a lower rated area. Fingertip sensing uses vision based tactile technology for distributed force information, resultant force measurement, texture recognition, and deformation feedback. A 300 point tactile sensing system across the palm expands contact awareness beyond the fingertips, supporting detailed interaction with objects during research tasks.
The direct drive architecture prioritizes accurate joint state data and responsive control, which are important for datasets, learning systems, and repeatable manipulation experiments. Fingertip tactile sensing supports force measurements from 0 to 30 N, with 0.005 N force resolution and 0.04 mm spatial resolution. The palm sensor provides 300 tactile pixels with 0.1 N resolution, extending touch feedback across the hand surface. Together, these sensing systems support contact rich work in which a controller must distinguish light contact, sustained pressure, texture, and object edges. The 4 out of 5 degrees of freedom rating highlights the hand’s emphasis on dexterity, while the 1 out of 5 strength rating provides a clear indication of its relative grip force position within the scoring framework.
OmniHand 3 Ultra M is in production and listed at 16,000 USD. It is manufactured by AGILINK, formally Shanghai AGILINK Innovation Intelligent Technology Co., Ltd., a Chinese robotics company. The hand has been validated through 500,000 cycles and is designed for continuous duty operation, with reported surface temperatures around 40 to 45°C under sustained load. Its combination of direct drive mechanics, encoder based positioning, fingertip tactile sensing, and palm contact sensing gives research teams a platform centered on measurable interaction data. This positioning is significant for laboratories and developers working on embodied AI, teleoperation, bimanual research, and manipulation systems that require consistent contact feedback during extended experimental sessions.