Welcome, RealBot 01!
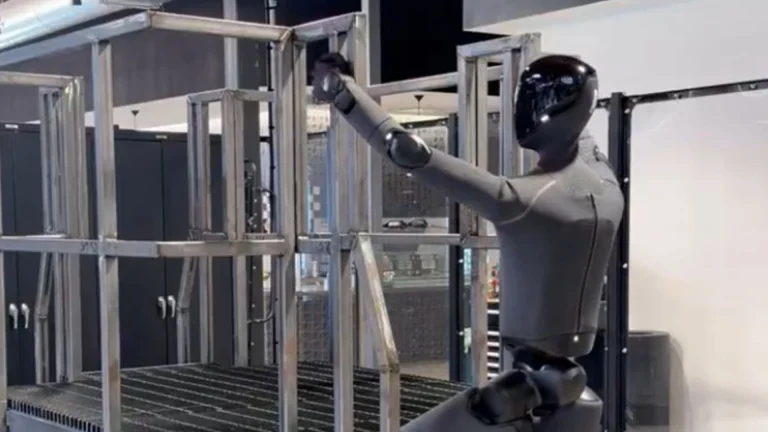
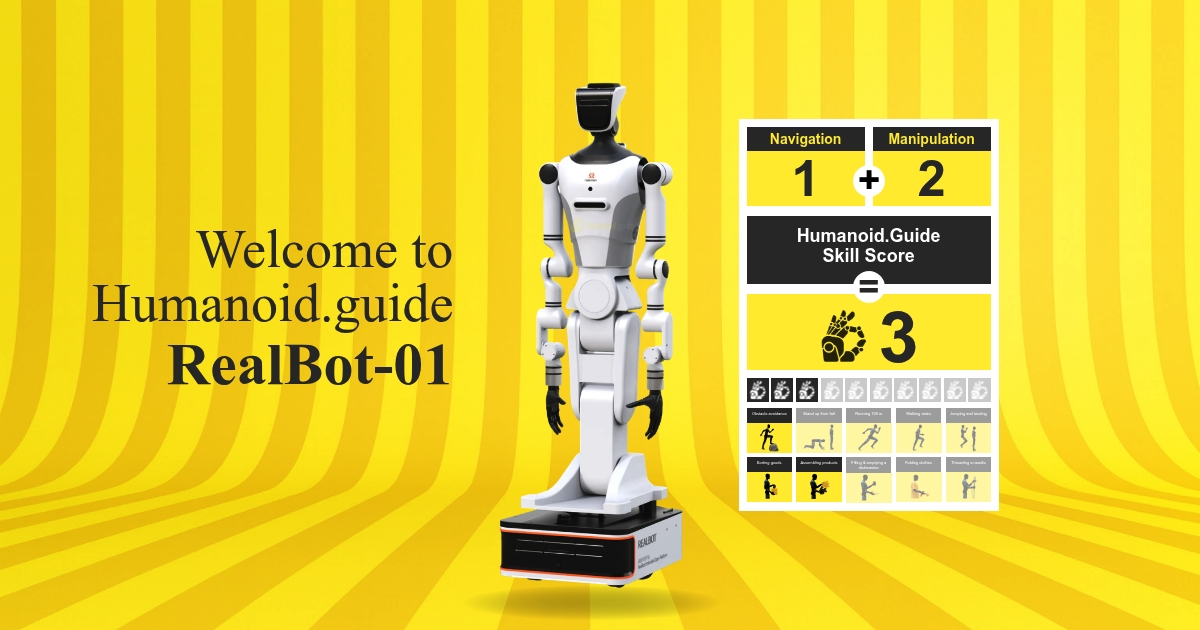
RealBot 01 is a wheeled humanoid robot from RealMan Robotics, combining a human shaped upper body with a mobile base for research, industrial automation, and mobile manipulation. It stands 168 cm tall, weighs 125 kg, and has a maximum travel speed of 5.4 km/h. Two articulated arms each support payloads of up to 5 kg, giving the platform a combined payload capacity of 10 kg. Its listed runtime is four hours per charge. The modular architecture allows the upper body to be separated from the chassis and integrated with compatible platforms, offering flexibility for different development environments. Standard configurations use two finger grippers, while optional five finger dexterous hands provide another hardware choice. An NVIDIA Jetson AGX Orin supplies computing resources, and the main controller runs Ubuntu 22.04 LTS with ROS 2 Humble. Its overall skill score of 3 out of 10 places it in the developing category, with manipulation rated above navigation. Operation around people requires suitable safeguards rather than an assumption of unrestricted collaborative safety.
Obstacle avoidance, sorting goods, and assembling products define the robot’s documented practical capabilities. Obstacle avoidance supports movement through work areas, while the wheeled format suits tasks distributed across multiple workstations. Sorting goods brings its paired arms into material handling workflows, with the 5 kg payload limit on each arm setting an important boundary for object selection. Product assembly provides another application for coordinated arm movements. These capabilities make the platform relevant to experiments that connect navigation with manipulation rather than treating mobility and arm operation as separate systems. Its navigation rating is 1 out of 5, and its manipulation rating is 2 out of 5. Those ratings describe developing proficiency, not counts of movements or completed tasks.
RealBot 01 is listed as in production, with a stated price of USD 30,000 and an inquiry option for buyers seeking a quotation. Its manufacturer, RealMan Robotics, is based in China. The platform targets embodied AI, industrial automation, home service, mobile manipulation, and robotic data collection markets. For prospective research and automation users, its broader significance lies in combining a mobile chassis, dual arms, modular construction, and a ROS 2 software environment in one platform. Ethernet and network based control interfaces provide connectivity for integration work. Procurement decisions should account for the selected gripper configuration, payload requirements, operating environment, and safeguards needed around people. Its developing skill rating makes evaluation against specific application requirements especially important.