LDA-1B
$ 0
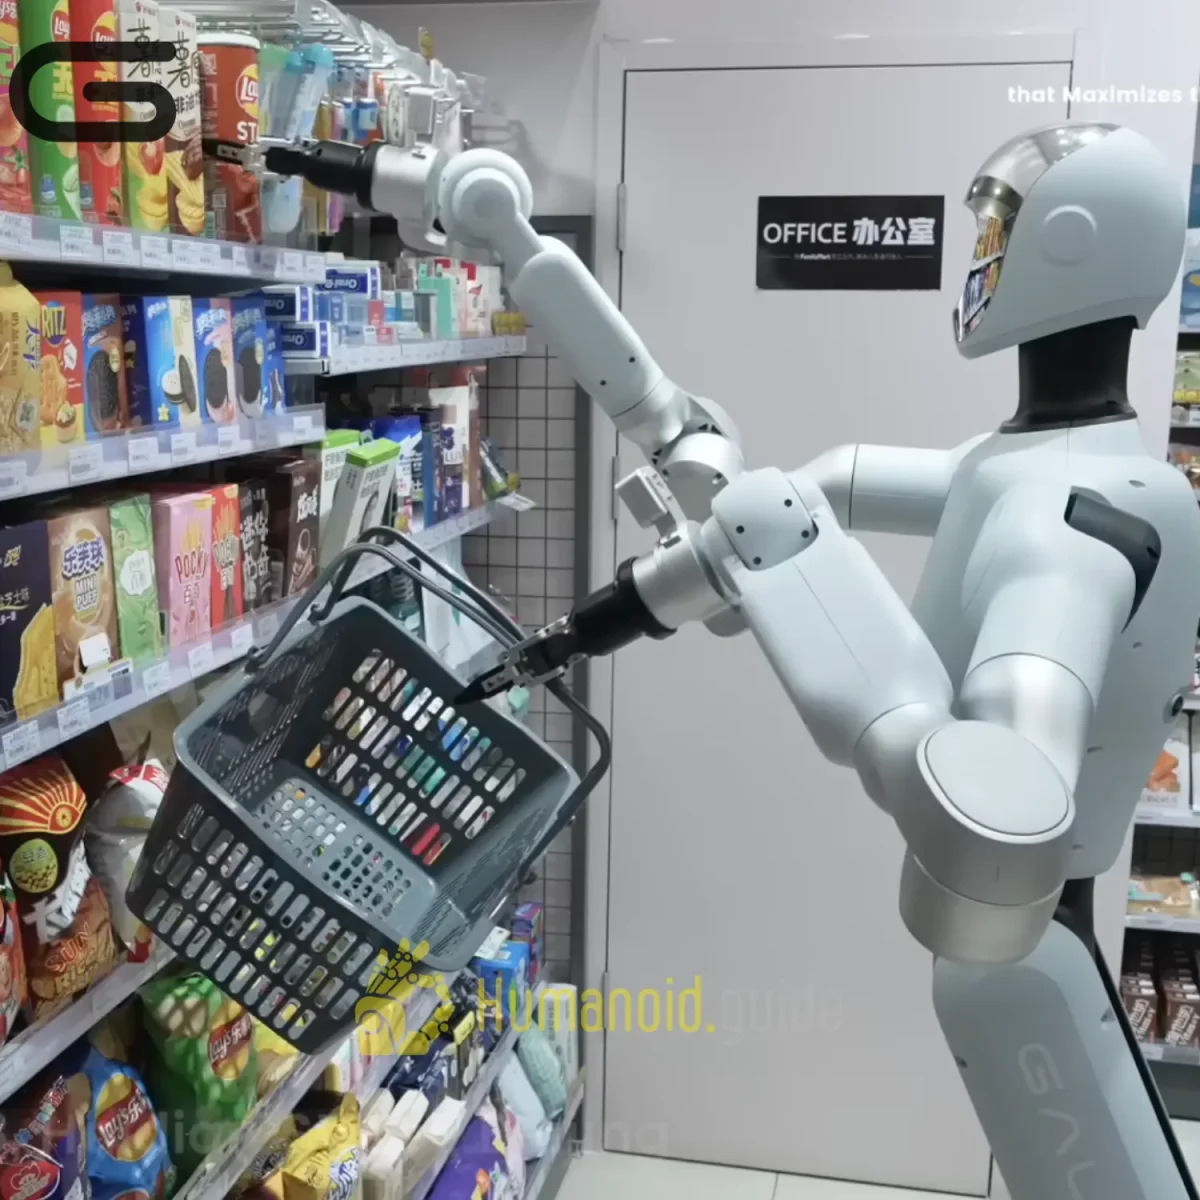
LDA-1B is a robot foundation model from Galbot and Peking University that learns both actions and how the world changes. It handles dexterous and long tasks on several robots.
Available on backorder
Brain Score
 4


Specifications and details:
| Nationality | China |
|---|---|
| Website | https://www.galbot.com/ |
| Model type | Foundation Model |
| Manufacturer | Beijing Galbot AI Co., Ltd. |
| Release date | February 12, 2026 |
Description
LDA-1B is a robot foundation model from Galbot and the EPIC Lab at Peking University. Partners from BAAI, Tsinghua University, CASIA, Sun Yat-sen University and NVIDIA also joined the work. Most robot models only copy expert demos, so they throw away a lot of useful data. LDA-1B takes another approach. It learns how the world changes, what will happen next and which action to take, all at once. Because of this, it can learn from messy or low-quality clips that other models usually discard.
The team trained the model on EI-30k, a new collection of about 30,000 hours of human and robot footage. With this base, robots can grasp, fold clothes, open an oven and handle objects with multi-finger hands. Galbot tested it on its G1 robot with both a simple gripper and a 22-joint dexterous hand. It also ran on a Unitree G1 humanoid with a BrainCo hand. In addition, the authors report clear gains over π0.5 on contact-rich, dexterous and long tasks. Anyone can download the pretrained weights from Hugging Face, and the code sits on GitHub.
New! 2026 Humanoid
Robot Market Report
198 pages of exclusive insight from global robotics experts — uncover funding trends, technology challenges, leading manufacturers, supply chain shifts, and surveys and forecasts on future humanoid applications.
now Google DeepMind
Contact Humanoid.guide
Website: https://pku-epic.github.io/LDA