Being-H0.5
$ 0
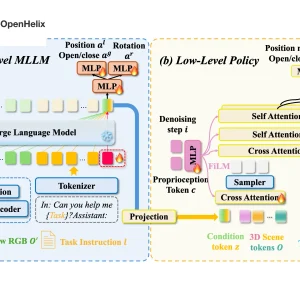
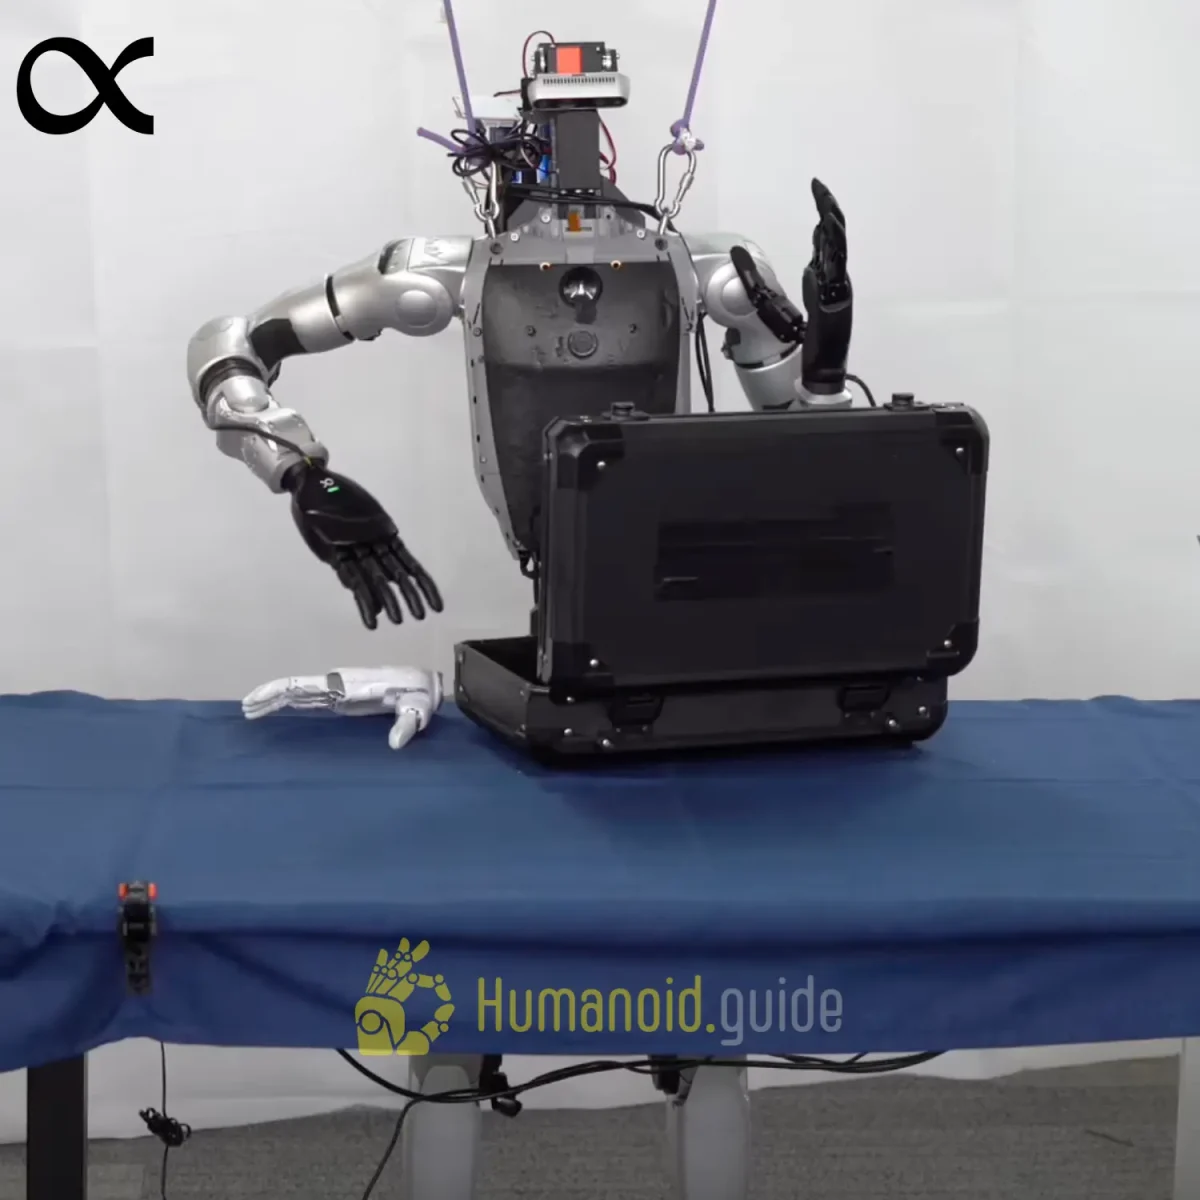
Being-H0.5 is BeingBeyond’s open robot model that learns from human hand activity to control many kinds of robots, from humanoids to dexterous arms.
Available on backorder
Brain Score
 5


Specifications and details:
| Nationality | China |
|---|---|
| Website | https://beingbeyond.com/en/ |
| Model type | Foundation Model |
| Manufacturer | BeingBeyond |
| Release date | January 19, 2026 |
Description
Being-H0.5 is a vision-language-action model from BeingBeyond, a Beijing robotics startup founded in 2025. The team released it in January 2026 as its main model for working across many robot bodies. Its core idea treats human hand activity as a shared language for physical work. So robots with little training data can borrow skills from human videos and from better-funded robots. The model learned from more than 35,000 hours of data across 30 robot types. As a result, it stands among the largest open efforts to build one brain for many different robots.
The team tested a single checkpoint on five real robots, including the Unitree G1, PND Adam-U and a Franka arm with Inspire hands. These tests covered two-handed work, dexterous hand tasks and long, multi-step jobs. In addition, a timing method lets the same model run on robots with different speeds and delays. It also scored 98.9% on the LIBERO benchmark and beat pi0.5, especially on long and two-armed tasks. Developers can download the 2B weights from Hugging Face, and the code sits on GitHub under Apache 2.0. Later, BeingBeyond built Being-H0.7 on top of this work.
New! 2026 Humanoid
Robot Market Report
198 pages of exclusive insight from global robotics experts — uncover funding trends, technology challenges, leading manufacturers, supply chain shifts, and surveys and forecasts on future humanoid applications.
now Google DeepMind
Contact Humanoid.guide