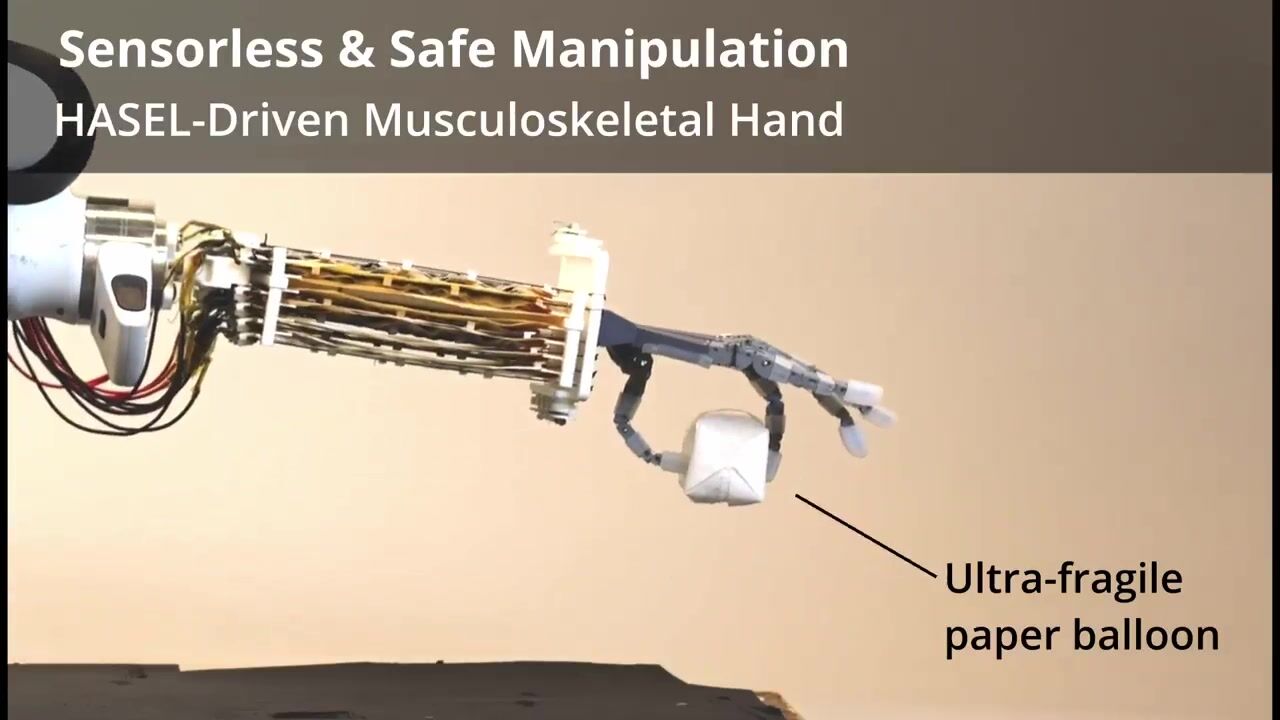
ETH Zurich presents Peano-HASEL musculoskeletal robot hand
Researchers associated with ETH Zurich’s Soft Robotics Lab have presented a musculoskeletal robotic hand powered entirely by remote Peano-HASEL electrohydraulic actuators. In a LinkedIn post, robotics professor Robert Katzschmann said the design places soft artificial muscles in the forearm and connects them to the hand through a compliant tendon driven architecture.
The team frames the system as an attempt to combine the safety and flexibility of soft actuation with dexterous multi finger grasping. Locating the actuators remotely is also intended to avoid adding bulky components to the hand itself. Katzschmann presented the approach as a way to pursue soft, safe manipulation without relying on expensive sensors, although the short announcement does not describe the sensing configuration.
For humanoid and dexterous manipulation developers, the relevant engineering choice is the separation between the artificial muscles and the hand mechanism. It preserves a musculoskeletal layout while keeping the actuation package in the forearm. The post does not provide quantitative grasp results, hand dimensions, degrees of freedom or comparisons with other actuator technologies, so the claimed balance of safety and dexterity cannot be assessed from the announcement alone. Katzschmann linked to a paper and a talk covering the work.
Source: Robert Katzschmann on LinkedIn