PHD-Hand
300 USD
New Jersey Institute of Technology (NJIT)
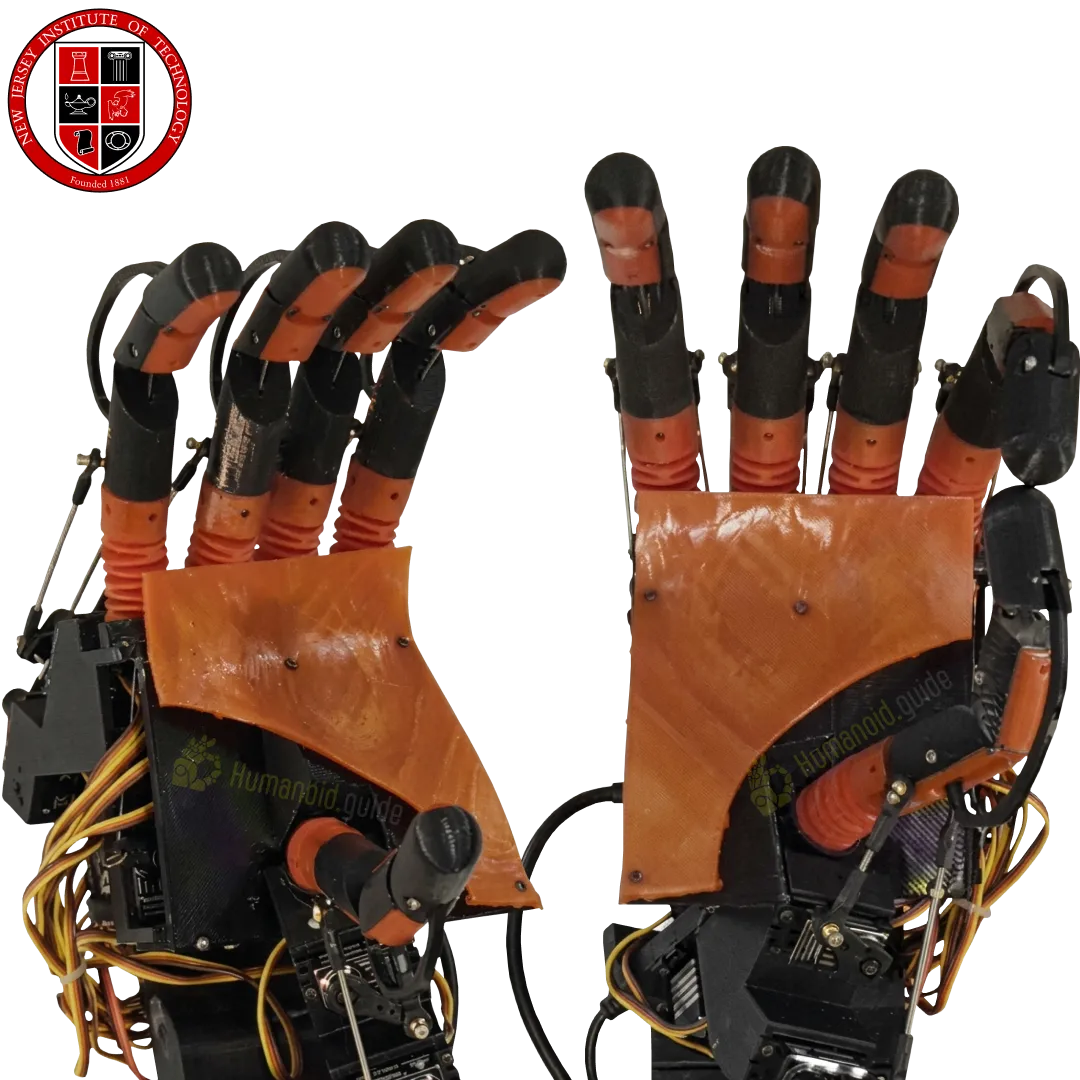
PHD-Hand is a 3D-printable, five-fingered humanoid robot hand from the New Jersey Institute of Technology. It moves its fingers with linkages instead of tendons, which makes it low-cost, durable and easy to build.
Hand Score
 4


Specifications and details:
| Availability | Prototype |
|---|---|
| Degrees of freedom, hands | 15 |
| Strength [kg] | 1 |
| Weight [kg] | 0.5 |
| Size | 200 mm |
| Number of fingers | 5 |
| Tactile/Force Sensors | No |
| Motor tech | Mini RC servos mounted outside the fingers, driving linkages (no tendons or gears) |
| Main structural material | 3D-printed PETG and TPU, with stainless spring-steel rods |
| Manufacturer | New Jersey Institute of Technology (NJIT) |
| Nationality | US |
| Website | https://phd-hand.github.io/ |
Description
PHD-Hand is a 3D-printable humanoid robot hand from researchers at the New Jersey Institute of Technology. The name stands for “Printable Humanoid Dexterous Hand.” The team introduced it in October 2026, and the paper is accepted to the IEEE-RAS Humanoids 2026 conference. Many advanced robot hands rely on tendons, which are costly, hard to maintain and wear out quickly. PHD-Hand takes a different approach. Instead, it moves its fingers with simple linkages, a flexible hinge and thin spring-steel rods. As a result, it avoids tendons and gear trains entirely.
2026 Humanoid Robot Market Report
Interested in the PHD-Hand? Download 198 pages of exclusive insight from global robotics experts — uncover funding trends, technology challenges, leading manufacturers, supply chain shifts, and surveys and forecasts on future humanoid applications.
humanoid expert
The hand has five digits, and each one has three independently controlled joints. Small hobby servo motors drive them from outside the fingers. Thanks to this design, anyone with a budget 3D printer can build the hand. It’s also close to the size of a human hand. In tests, PHD-Hand performed all 33 standard human grasp types, though a few still need work. It also turned a precision screwdriver, flipped a jar lid and rotated a cube in its fingers. Moreover, the team ran one prototype for about 200 hours. The researchers plan to release the design files openly soon.
Download the Humanoid Robot Market Report here
Website: https://phd-hand.github.io/