MM-Hand 1.0
1 400 USD
MMLab, The University of Hong Kong (HKU)
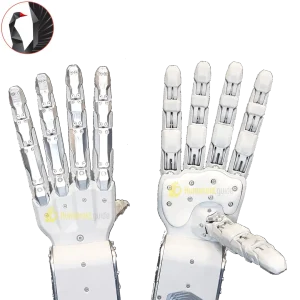
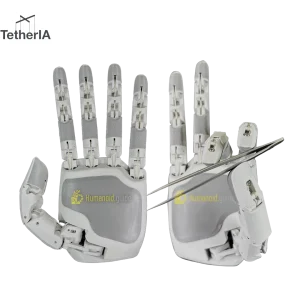
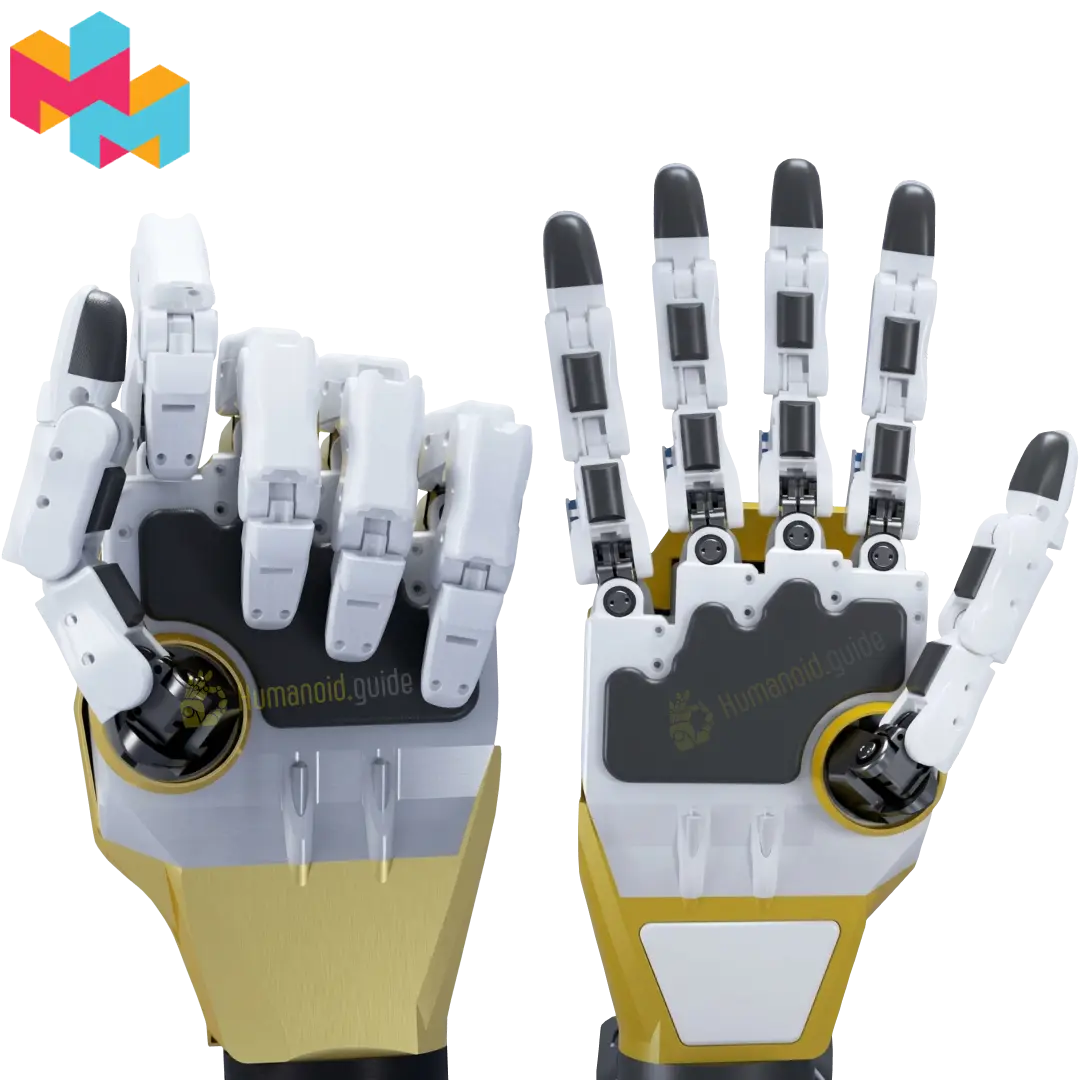
MM-Hand 1.0 is HKU MMLab’s open-source, remote tendon-driven dexterous hand with 21 fully actuated DoF. The ~350 g hand carries tactile sensors, joint angle sensors and palm cameras, with about $1,400 in material cost.
Hand Score
 5


Specifications and details:
| Availability | Prototype |
|---|---|
| Degrees of freedom, hands | 21 |
| Strength [kg] | 2 |
| Weight [kg] | 0.35 |
| Size | N/A |
| Number of fingers | 5 |
| Tactile/Force Sensors | Yes: 15 tactile sensors (1 mm spatial, 0.1 N force resolution), 21 joint angle sensors, 21 tendon tension sensors, 2 palm cameras (140° field of view, controllable LED), plus motor-side feedback |
| Motor tech | 21 remote motors in an external motor hub driving spring-return tendons through sheaths / standard TTL/CAN servo motors |
| Main structural material | 3D-printed plastic (modular finger and palm parts) |
| Manufacturer | MMLab, The University of Hong Kong (HKU) |
| Nationality | China |
| Website | https://mmlab.hk/ |
Description
MM-Hand 1.0 is an open-source, tendon-driven dexterous hand from MMLab at the University of Hong Kong. Unlike most robotic hands, it keeps its motors outside the hand, in a separate motor hub. Tendons running through flexible sheaths carry the motors’ force to the fingers. As a result, the hand stays light, never overheats, and leaves room inside for more joints and sensors. Every one of its 21 joints has its own motor, which makes it one of the most dexterous hands available.
2026 Humanoid Robot Market Report
Interested in the MM-Hand 1.0? Download 198 pages of exclusive insight from global robotics experts — uncover funding trends, technology challenges, leading manufacturers, supply chain shifts, and surveys and forecasts on future humanoid applications.
humanoid expert
The hand also packs in a rich set of sensors. For example, it uses tactile sensors in the fingertips, angle sensors in every joint and two small cameras in the palm. In addition, quick-release tendon connectors let users swap a finger or motor in moments. Its 3D-printed parts and Arduino-based control make it easy to modify. Therefore, it gives researchers an affordable, open platform for studying dexterous manipulation, with the full design, electronics and software freely shared.
Download the Humanoid Robot Market Report here
Website: https://mmlab.hk/research/MM-Hand