TORCH HAND 2
6 500 USD
TorchKernel Robotics (炬坤机器人)
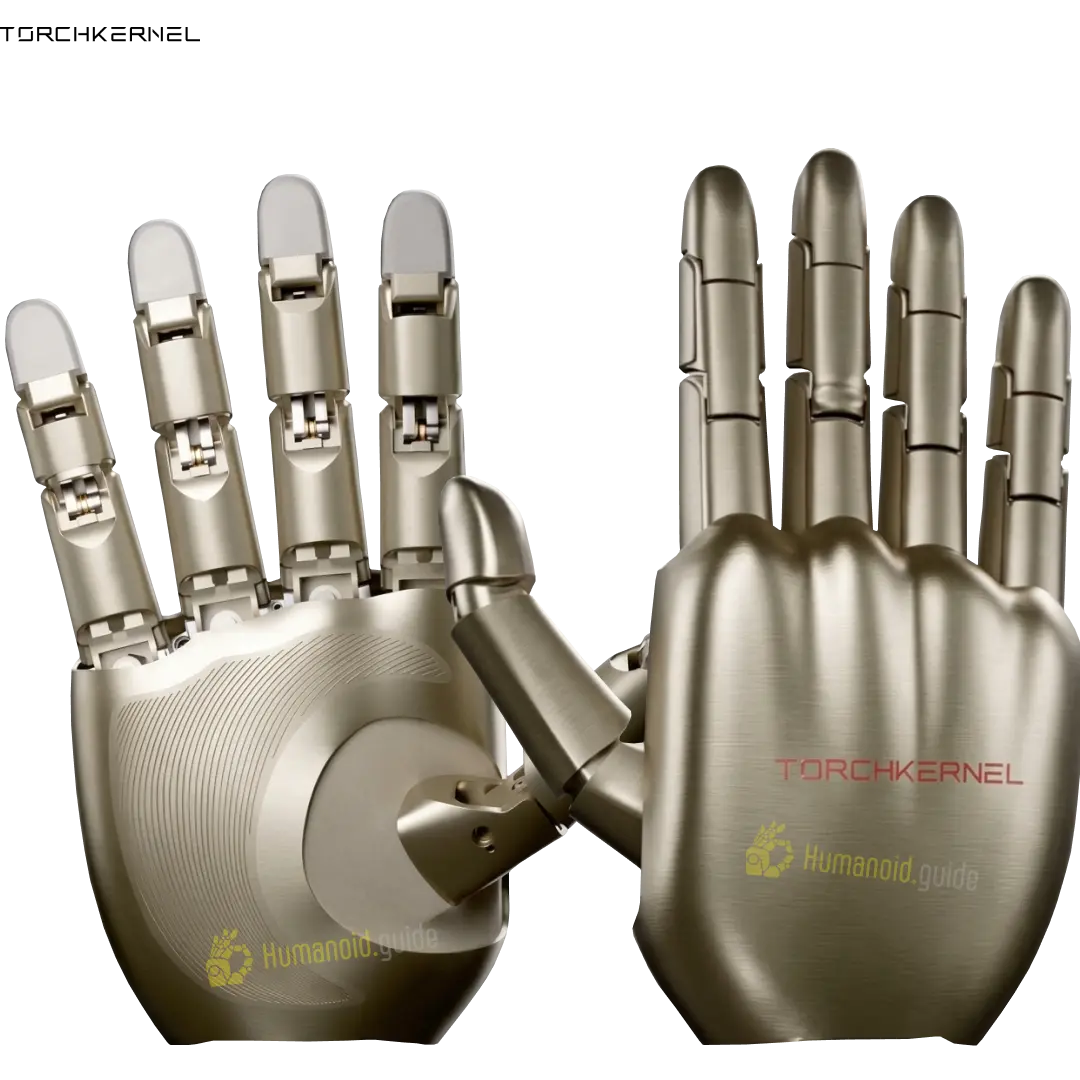
A lightweight, sensor-dense hand from TorchKernel Robotics with 320 tactile pixels, a perfect Kapandji dexterity score, and 0.01N force resolution.
Hand Score
 6


Specifications and details:
| Availability | In production |
|---|---|
| Degrees of freedom, hands | 20 |
| Strength [kg] | 20 |
| Weight [kg] | 0.48 |
| Size | 200mm × 105mm × 50mm |
| Number of fingers | 5 |
| Tactile/Force Sensors | Yes — 320 tactile pixels at 64 units/cm², dual-mode resistive + capacitive sensing, 0.01N force resolution, 0–30N force range, 0.2mm spatial resolution |
| Motor tech | N/A |
| Main structural material | N/A |
| Manufacturer | TorchKernel Robotics (炬坤机器人) |
| Nationality | China |
| Website | https://www.torchkernel.com/ |
Description
TorchKernel Robotics also builds the TORCH HAND 2, a lighter, sensor-focused sibling to its first hand. It packs sixteen active joints and four passive ones into a compact five-fingered design. At just 480 grams, it weighs less than half of the original TORCH-HAND 1. Because of that lighter build, it suits robots where every gram of end-effector weight matters. The hand also passed the Kapandji test with a perfect score. That test measures how well a thumb can reach and rotate toward each finger. So the result points to genuinely human-like dexterity, not just raw joint count.
2026 Humanoid Robot Market Report
Interested in the TORCH HAND 2? Download 198 pages of exclusive insight from global robotics experts — uncover funding trends, technology challenges, leading manufacturers, supply chain shifts, and surveys and forecasts on future humanoid applications.
humanoid expert
Sensing is where this hand truly stands out. Its surface carries 320 individual tactile sensing points, packed at 64 units per square centimeter. These sensors combine two different sensing types, resistive and capacitive, to pick up both light touches and firmer contact. As a result, the hand can detect forces as small as 0.01N. It can also register forces up to 30N at a single point. It also tracks contact location with 0.2mm spatial resolution, which is remarkably fine-grained for a robotic hand. A standard EtherCAT or UART interface connects it to a robot’s main controller. So it fits easily into existing industrial setups. Overall, the TORCH HAND 2 trades some of the first hand’s raw grip strength for exceptional tactile awareness and a lighter, more agile frame.
Download the Humanoid Robot Market Report here
Website: www.torchkernel.com